FANUC_A2_SPINDLE_VF_ENC #
Fanuc alpha 2 induction spindle motor, fan cooled
[plate] A06B-0852-B190#3000, delta, 4 poles
(2 pole pairs), S1 2.2 kW 19 A rms (26.9 pk),
S2 15 min / S3 60 % 3.7 kW 27 A rms, 14.0 Nm,
base 1500 rpm, max 8000 rpm, J 0.0078 kgm2,
110-216 V, overload 120 % of 30 min, 1 min
idacim input: 155 V at 78.4 Hz (2352 rpm)
original Fanuc amp: SPM-5.5 A06B-6078-H206#H500,
27 A rms, 200-230 V in; parameters (FS16i,
B-65160E/02 app. C, units not recorded):
4020 max speed 8000, 4100 power base 1750,
4101 100, 4102 base speed 2352, 4103 flux
down start 2352, 4104/4105 cur P 1300,
4106/4107 cur I 1500, 4108 300, 4110 585,
4111 22, 4112 783, 4113 slip 450, 4114 high
speed slip comp 10, 4115 dead time comp 2,
motor model code 103
[id] 13 Oct 2026 from a clean config, no hand
values: idacim (standstill, rotating,
ramps tr) + pole/direction test, id_sys
on the encoder, conf0.max_force =
acim_foc0.t_max, id_pid speed mode
(idacim_rot_tr df22b814)
checked 13 Oct: +-838 rad/s, holds 0 (field
stops at a 0 command), no fault
variant: V/f with encoder slip control.
speed: vf0.vel_cmd [rad/s mech]; enable: fault0.en
Configuration Content #
# Fanuc alpha 2 induction spindle motor, fan cooled
# [plate] A06B-0852-B190#3000, delta, 4 poles
#   (2 pole pairs), S1 2.2 kW 19 A rms (26.9 pk),
#   S2 15 min / S3 60 % 3.7 kW 27 A rms, 14.0 Nm,
#   base 1500 rpm, max 8000 rpm, J 0.0078 kgm2,
#   110-216 V, overload 120 % of 30 min, 1 min
# idacim input: 155 V at 78.4 Hz (2352 rpm)
# original Fanuc amp: SPM-5.5 A06B-6078-H206#H500,
#   27 A rms, 200-230 V in; parameters (FS16i,
#   B-65160E/02 app. C, units not recorded):
#   4020 max speed 8000, 4100 power base 1750,
#   4101 100, 4102 base speed 2352, 4103 flux
#   down start 2352, 4104/4105 cur P 1300,
#   4106/4107 cur I 1500, 4108 300, 4110 585,
#   4111 22, 4112 783, 4113 slip 450, 4114 high
#   speed slip comp 10, 4115 dead time comp 2,
#   motor model code 103
# [id] 13 Oct 2026 from a clean config, no hand
#   values: idacim (standstill, rotating,
#   ramps tr) + pole/direction test, id_sys
#   on the encoder, conf0.max_force =
#   acim_foc0.t_max, id_pid speed mode
#   (idacim_rot_tr df22b814)
# checked 13 Oct: +-838 rad/s, holds 0 (field
# stops at a 0 command), no fault
# variant: V/f with encoder slip control.
# speed: vf0.vel_cmd [rad/s mech]; enable: fault0.en
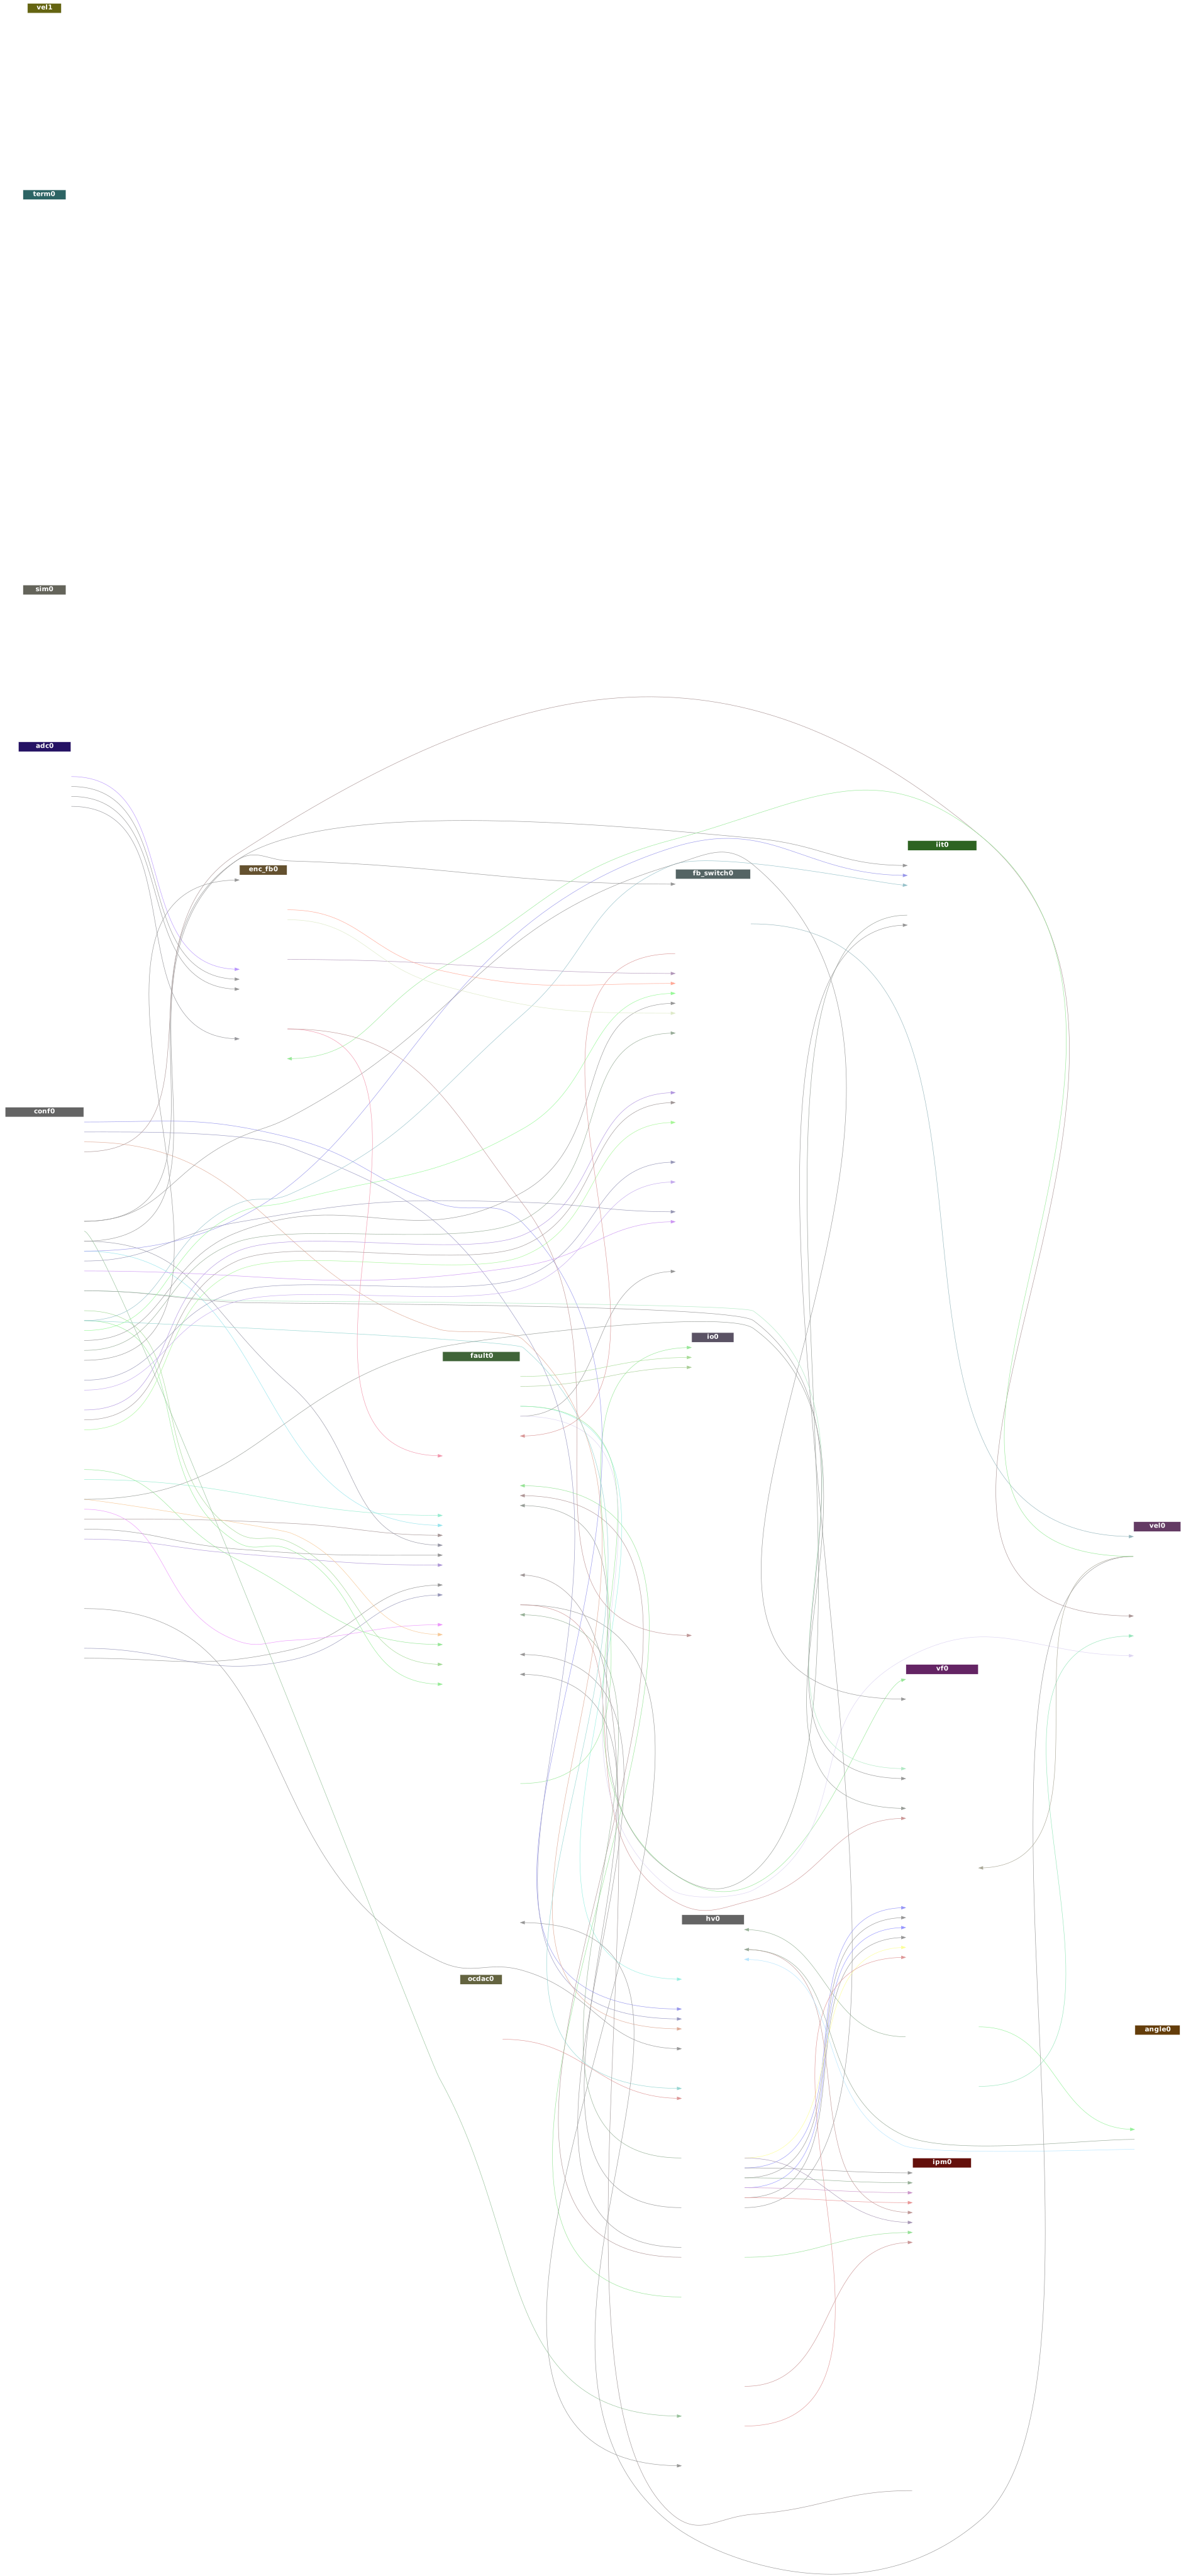
link vf_enc
# encoder: 512 line sin/cos (magnetic) on fb0
link enc_fb0
conf0.mot_fb_res = 512
enc_fb0.ires = 32
fb_switch0.mot_pos = enc_fb0.ipos
adc0.sin_gain = 1.5 # magnetic encoder, low amp
adc0.cos_gain = 1.5
enc_fb0.vel = vel0.vel
# drive: IM06B50GC1 bridge, water cooled
link ipm_im06b50gc1
link ocdac
ocdac0.dac0 = 128 # 0xC break filter map, 6 Oct
ocdac0.k = 6.48
ocdac0.cur = 36 # above the F3 software trips
conf0.max_ac_cur = 32 # S2 peak; F3 trips 33.25
conf0.max_dc_cur = 30
iit0.cur_boost = 1.1896 # S1 26.9 A pk
iit0.max_time = 1452 # S2 32 A for 30 min
hv0.drop_k = 0.885 # board dead time comp
hv0.drop_knee = 0.85
conf0.polecount = 2 # [plate]
conf0.max_vel = 838 # [plate] 8000 rpm
conf0.max_acc = 97.5 # 65% of the belt's 150
# idacim 13 Oct 15:52 (157ab726), pp test 15:57
conf0.out_rev = 1 # [idacim pp]
conf0.r = 0.193065 # [idacim]
conf0.l = 0.000747 # [idacim]
conf0.j = 0.012124 # [idacim]
vf0.u_n = 126.557 # [idacim]
vf0.vel_n = 246.301 # [idacim]
vf0.u_boost = 14.4585 # [idacim]
vf0.boost_vel = 20.0923 # [idacim]
vf0.slip_n = 6.08924 # [idacim]
vf0.cur_n = 20.1125 # [idacim]
vf0.acc = conf0.max_acc
vf0.dec = conf0.max_acc
fault0.en = 0 # set 1 to run
Source: Configuration File