FANUC_A3-3000 #
Fanuc alpha 3/3000, ball screw 10 mm/rev,
absolute Fanuc encoder, LinuxCNC on sserial.
Kira Y axis with its load, 9 Oct 2026.
Sources, marked per line:
[plate] nameplate / Fanuc datasheet
[id] measured with the id_* templates
[calc] derived from the lines above it
Fanuc gives currents in A rms; STMBL currents are
peak (A pk = A rms x 1.414).
[plate] nameplate A06B-0123-B075 (04.02):
0.9 kW cont., 127 V, 4.6 A rms, 200 Hz at
3000 rpm, class F, Y connected, 200 V amp,
stall 3 Nm at 4.6 A rms
[plate] datasheet B-65142E/02 (rms, 20 C):
max 3000 rpm, 4 pole pairs, Jm 0.0014 kgm2
Ts 3.0 Nm, Is 4.6 A rms = 6.5 A pk
Kt 0.65 Nm/A rms, Ke 23 V rms/1000 rpm
Kv 0.22 Vs/rad (psi about 0.077)
Ra 0.57 ohm/phase, thermal tc 45 min
mech tc 6 ms, static friction 0.3 Nm
max current 60 A pk, max torque 27 Nm
[plate] stock Fanuc amp (B-65162, labels):
X: A06B-6079-H204 SVM2-12/40, M channel
Y: A06B-6079-H207 SVM2-40/80, L channel
both: 12.5 A rms rated, 40 A pk limit
(about 16.8 Nm with this motor’s psi)
measured on this motor for comparison:
DMM R line-line 1.34-1.37 ohm
LCR 1 kHz L line-line 6.6-6.8 mH
psi 0.0702 = 0.91 x datasheet
Configuration Content #
# Fanuc alpha 3/3000, ball screw 10 mm/rev,
# absolute Fanuc encoder, LinuxCNC on sserial.
# Kira Y axis with its load, 9 Oct 2026.
#
# Sources, marked per line:
#   [plate] nameplate / Fanuc datasheet
#   [id]    measured with the id_* templates
#   [calc]  derived from the lines above it
# Fanuc gives currents in A rms; STMBL currents are
# peak (A pk = A rms x 1.414).
#
# [plate] nameplate A06B-0123-B075 (04.02):
#   0.9 kW cont., 127 V, 4.6 A rms, 200 Hz at
#   3000 rpm, class F, Y connected, 200 V amp,
#   stall 3 Nm at 4.6 A rms
# [plate] datasheet B-65142E/02 (rms, 20 C):
#   max 3000 rpm, 4 pole pairs, Jm 0.0014 kgm2
#   Ts 3.0 Nm, Is 4.6 A rms = 6.5 A pk
#   Kt 0.65 Nm/A rms, Ke 23 V rms/1000 rpm
#   Kv 0.22 Vs/rad (psi about 0.077)
#   Ra 0.57 ohm/phase, thermal tc 45 min
#   mech tc 6 ms, static friction 0.3 Nm
#   max current 60 A pk, max torque 27 Nm
# [plate] stock Fanuc amp (B-65162, labels):
#   X: A06B-6079-H204 SVM2-12/40, M channel
#   Y: A06B-6079-H207 SVM2-40/80, L channel
#   both: 12.5 A rms rated, 40 A pk limit
#   (about 16.8 Nm with this motor's psi)
# measured on this motor for comparison:
#   DMM R line-line 1.34-1.37 ohm
#   LCR 1 kHz L line-line 6.6-6.8 mH
#   psi 0.0702 = 0.91 x datasheet
link pid
link pmsm
link filters
link misc
link fanuc_fb0
link ocdac
link sserial
# feedback: absolute encoder, linrev in mm
# the scale comes from LinuxCNC:
#   setp hm2_7i94.0.stbl.0.N.scale 10
encf0.pos_offset = 0
linrev0.abs_en = 1
linrev0.abs_rev = encf0.turns
linrev0.abs_pos = encf0.pos
linrev0.abs_state = encf0.state
linrev0.abs_neg = conf0.mot_fb_rev
# motor
conf0.polecount = 4 # [id] pole pairs
conf0.out_rev = 1
conf0.r = 0.661196 # [id] id_pmsm, ohm
conf0.l = 0.003201 # [id] Ld, H
conf0.lq = 0.004308 # [id] Lq, H
conf0.psi = 0.070176 # [id] emf0; [plate] 0.077
# [calc] Kt = 1.5 x 4 x psi = 0.421 Nm/A pk
#        = 0.596 Nm/A rms; at Is: 2.74 Nm
conf0.j = 0.001625 # [id] id_mot, rotor kgm2
conf0.mot_fb_offset = 0.522777 # [id] id_pmsm
conf0.com_fb_offset = 2.098459 # [id] id_pmsm
pmsm_ttc0.mtpa = 1 # Ld < Lq, MTPA pays
hv0.drop_k = 0.938142 # [id] id_pmsm
hv0.drop_knee = 0.975 # [id] id_pmsm
hv0.adv = 0.000376 # [id] id_tune
# limits
conf0.max_vel = 314.159265 # [plate] 3000 rpm
conf0.max_acc = 20000
conf0.max_ac_cur = 16.3 # 2.5 x Is, by choice
conf0.max_force = 6.86 # [calc] 16.3 A x Kt
conf0.low_dc_volt = 200
iit0.cur_boost = 2.5 # cont. 6.5 A pk = Is
iit0.max_time = 605 # [plate] tt 45 min
# over current comparator: drive specific,
# measure per board (ocdac map, 6 Oct)
ocdac0.dac0 = 144
ocdac0.k = 6.53
ocdac0.cur = 21.2 # 1.3 x max_ac_cur
# stopping
fault0.rstop_en = 1 # regen stop first
fault0.sbrake_en = 1 # short brake fallback
hv io0.sbrake_cur = 8 # f3 chop
# load + loop: axis specific, redo per machine
# id_sys / id_lpf / id_pid, 9 Oct 2026
conf0.j_sys = 0.002310 # [id] motor + load
# friction ff off: dob0 estimates friction too
# (id_sys: f 0.526805, d 0.010228, o -0.001081)
conf0.f = 0
conf0.d = 0
conf0.o = 0
# dob: load torque observer, 15 Oct 2026
# 2-30x load stiffness at 2-25 Hz, LinuxCNC
# f-error ~1 um rms worse than friction ff
dob0.j = 0.003935 # [id] id_frf total
dob0.max = 3
dob0.k = 1
# standstill hold with dob (bench 23 Oct: +-1 A -> 0 A
# at rest, arms at one count in 0.2 s, rest < 1.2 mrad)
pid0.hold_en = 2
conf0.j_lpf = 13 # [bench] Y FRF, id_lpf 17.55, Hz
conf0.pos_bw = 25 # [id] id_pid
# position axis: velocity feedback and velocity ff without timing lag
vel1.vel_p = 1
vel_int0.vel_ip = 1
conf0.vel_bw = 400 # [id] cap cur_bw / 7.5
conf0.vel_d = 5 # [id] id_pid
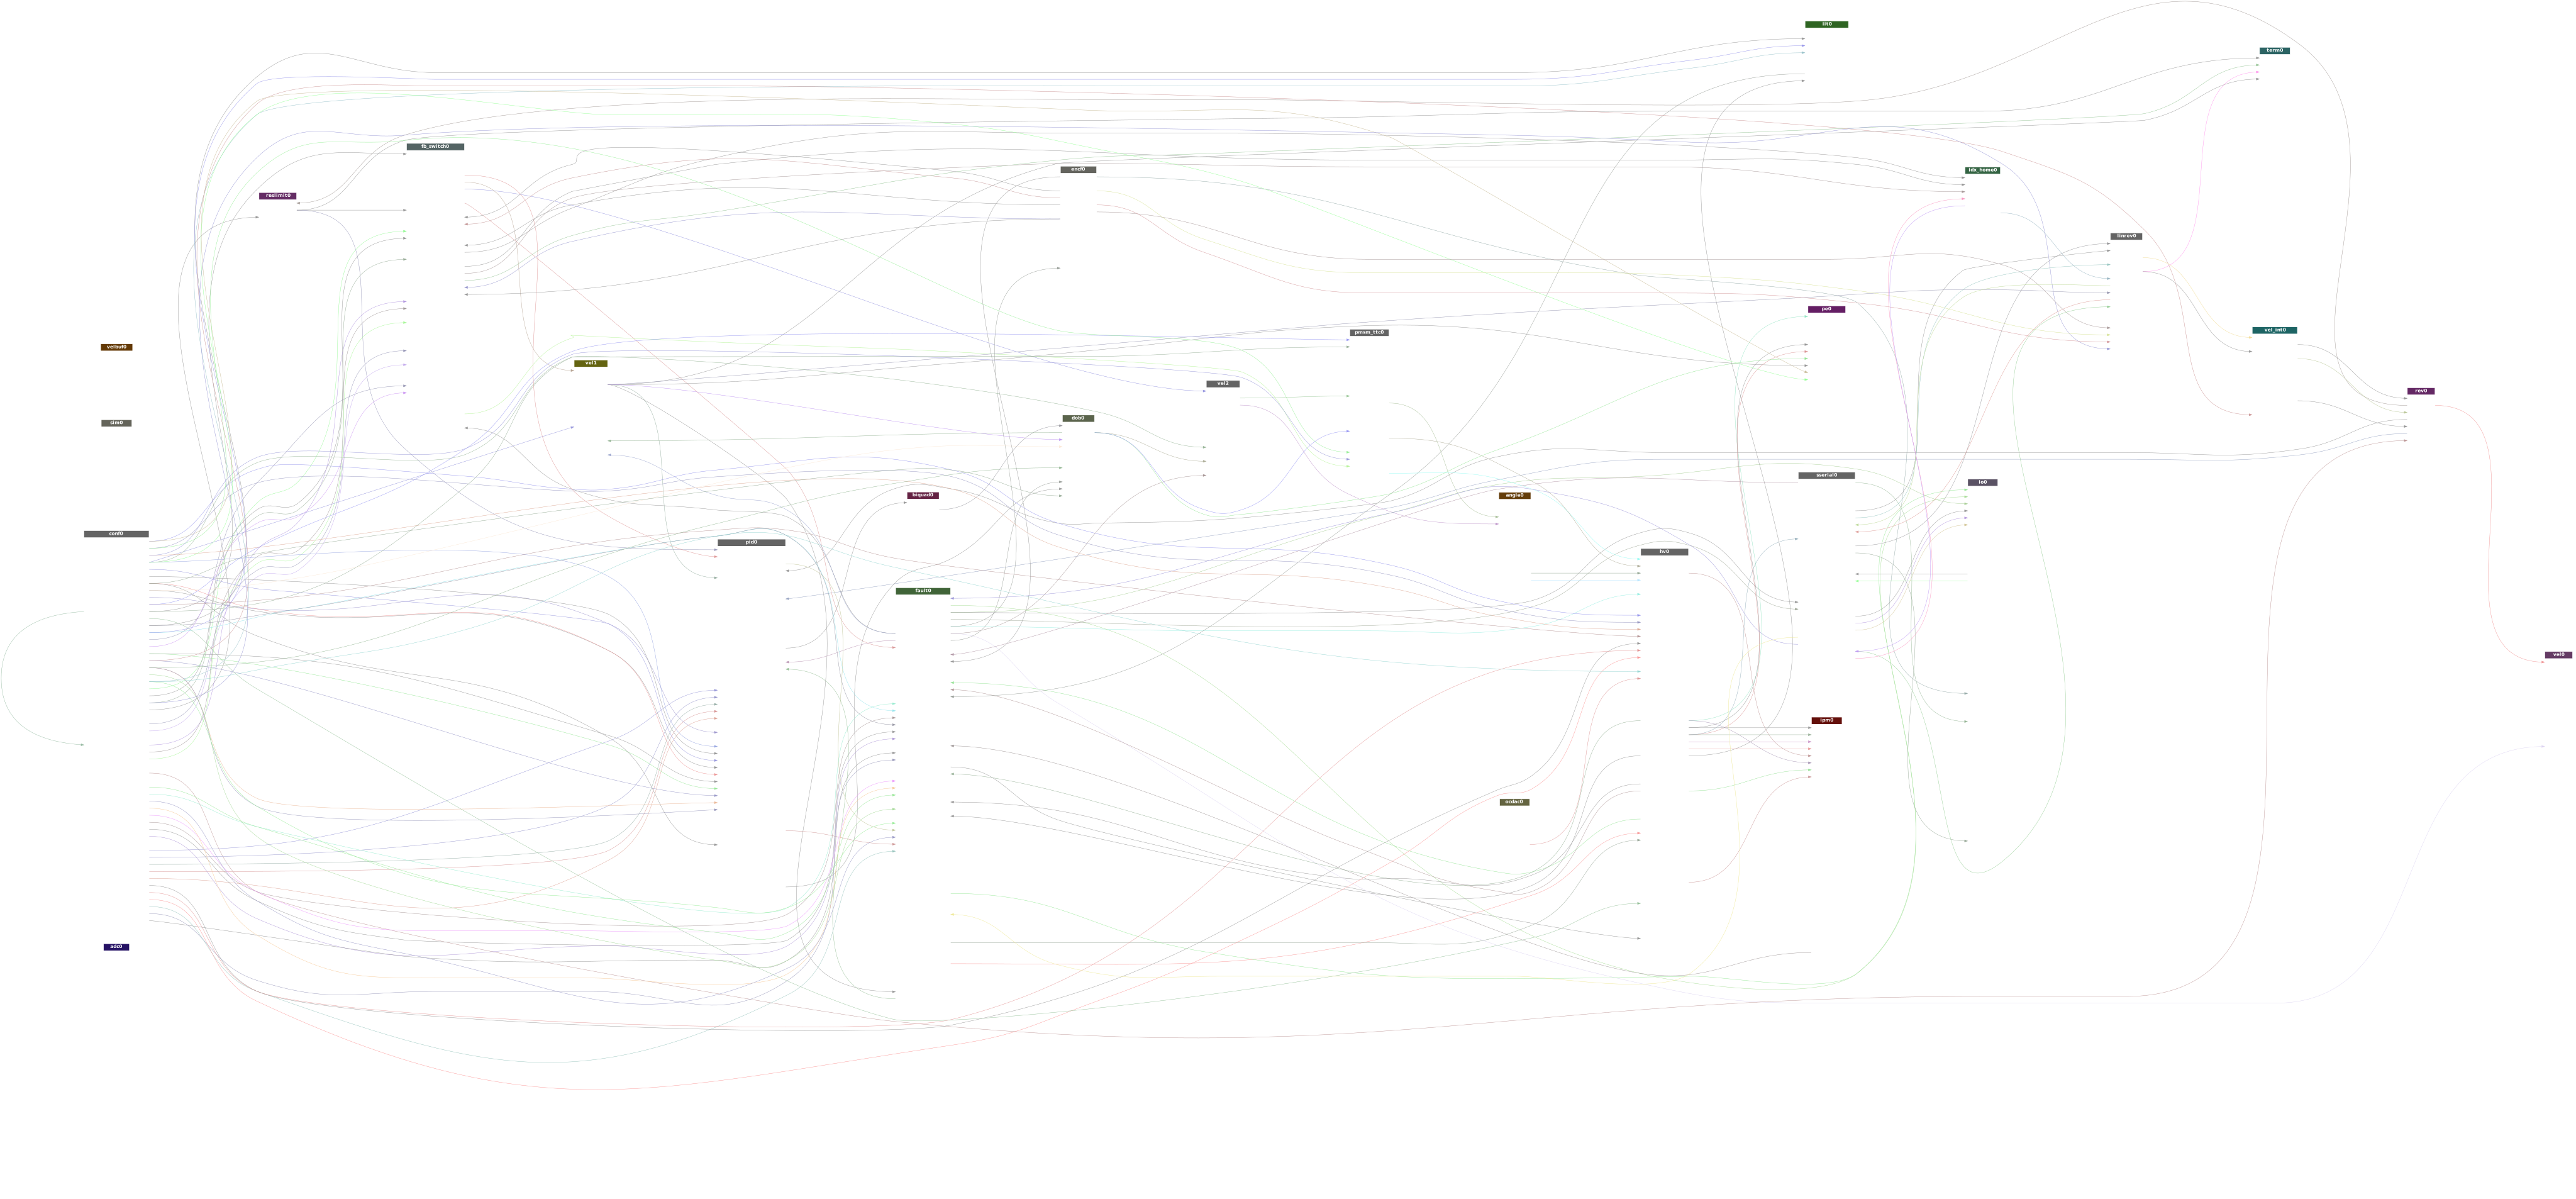
Source: Configuration File