ACIM_FOC #
induction motor, rotor flux orientation on the encoder.
link after pid: link pid, link acim_foc. Needs in the config:
acim_flux0.tr, acim_flux0.lmr (idacim), acim_foc0.id_n,
conf0.l = sigma*Ls (leakage), conf0.lq 0, conf0.psi 0.
field weakening: acim_fw0.duty = hv0.duty (optional)
optional, all off by default; values that fit any motor:
acim_foc0.k_boost 2, acim_foc0.boost_max 0.3 (flux boost)
acim_flux0.tr_flux_min 0.95, tr_acc_max 0.3 (tr MRAS gates;
tr_ki is per motor, spindle 1e-4; tr_iq_min about 0.03 x id_n
to adapt at no load)
acim_flux0.lmr_sat from idacim; i_knee, tr_sat from a tr map
acim_flux0.lmr_ki 0.5: lmr trim, for checking lmr_sat
fluxopt0.min 0.5: light-load flux reduction (1 = off,
default); lower flux at idle, less torque on a
sudden load until the flux is back (tr)
Configuration Content #
# induction motor, rotor flux orientation on the encoder.
# link after pid: link pid, link acim_foc. Needs in the config:
# acim_flux0.tr, acim_flux0.lmr (idacim), acim_foc0.id_n,
# conf0.l = sigma*Ls (leakage), conf0.lq 0, conf0.psi 0.
# field weakening: acim_fw0.duty = hv0.duty (optional)
# optional, all off by default; values that fit any motor:
# acim_foc0.k_boost 2, acim_foc0.boost_max 0.3 (flux boost)
# acim_flux0.tr_flux_min 0.95, tr_acc_max 0.3 (tr MRAS gates;
# tr_ki is per motor, spindle 1e-4; tr_iq_min about 0.03 x id_n
# to adapt at no load)
# acim_flux0.lmr_sat from idacim; i_knee, tr_sat from a tr map
# acim_flux0.lmr_ki 0.5: lmr trim, for checking lmr_sat
# fluxopt0.min 0.5: light-load flux reduction (1 = off,
# default); lower flux at idle, less torque on a
# sudden load until the flux is back (tr)
load acim_fw
load acim_flux
load acim_foc
load fluxopt
acim_fw0.rt_prio = 8.5
acim_flux0.rt_prio = 8.6
fluxopt0.rt_prio = 8.65
acim_foc0.rt_prio = 8.7
acim_fw0.en = fault0.en_out
acim_fw0.vel = angle0.vel
acim_fw0.polecount = conf0.polecount
acim_fw0.pwm_volt = hv0.pwm_volt
acim_fw0.id_n = acim_foc0.id_n
# feedforward on l + lmr; ki from tr (acim_fw0.ki 0); a config ls or ki wins
acim_fw0.l = conf0.l
acim_fw0.lmr = acim_flux0.lmr_act
acim_fw0.tr = acim_flux0.tr_act
# acim_fw0.p_max = the motor's S1 power; it gets iit0's overload headroom
acim_fw0.p_boost = iit0.cur_boost
acim_flux0.en = fault0.en_out
acim_flux0.id = hv0.id_fb
acim_flux0.iq = hv0.iq_fb
acim_flux0.polecount = conf0.polecount
acim_flux0.ud = hv0.ud_fb
acim_flux0.uq = hv0.uq_fb
acim_flux0.vel = angle0.vel
acim_flux0.l = conf0.l
acim_flux0.r = conf0.r
acim_flux0.max_acc = conf0.max_acc
acim_foc0.en = fault0.en_out
acim_foc0.torque = pid0.torque_cmd
fluxopt0.torque = pid0.torque_cmd
fluxopt0.scale_in = acim_fw0.scale
fluxopt0.id_n = acim_foc0.id_n
fluxopt0.lmr = acim_flux0.lmr_act
fluxopt0.polecount = conf0.polecount
acim_foc0.scale = fluxopt0.scale
acim_foc0.t_lim = acim_fw0.t_lim
acim_foc0.i_mr = acim_flux0.i_mr
acim_foc0.lmr = acim_flux0.lmr_act
acim_flux0.i_n = acim_foc0.id_n
acim_foc0.max_cur = conf0.max_ac_cur
acim_foc0.polecount = conf0.polecount
pid0.max_torque = acim_foc0.t_max
pid0.neg_min_torque = acim_foc0.t_max
pid0.max_vel = conf0.max_vel
angle0.src = 1
angle0.polecount = conf0.polecount
angle0.pos_m = fb_switch0.vel_fb
angle0.vel_m = vel1.vel
angle0.slip = acim_flux0.slip
hv0.d_cmd = acim_foc0.d_cmd
hv0.q_cmd = acim_foc0.q_cmd
hv0.cmd_mode = 1
hv0.phase_mode = 2
hv0.psi = acim_flux0.psi
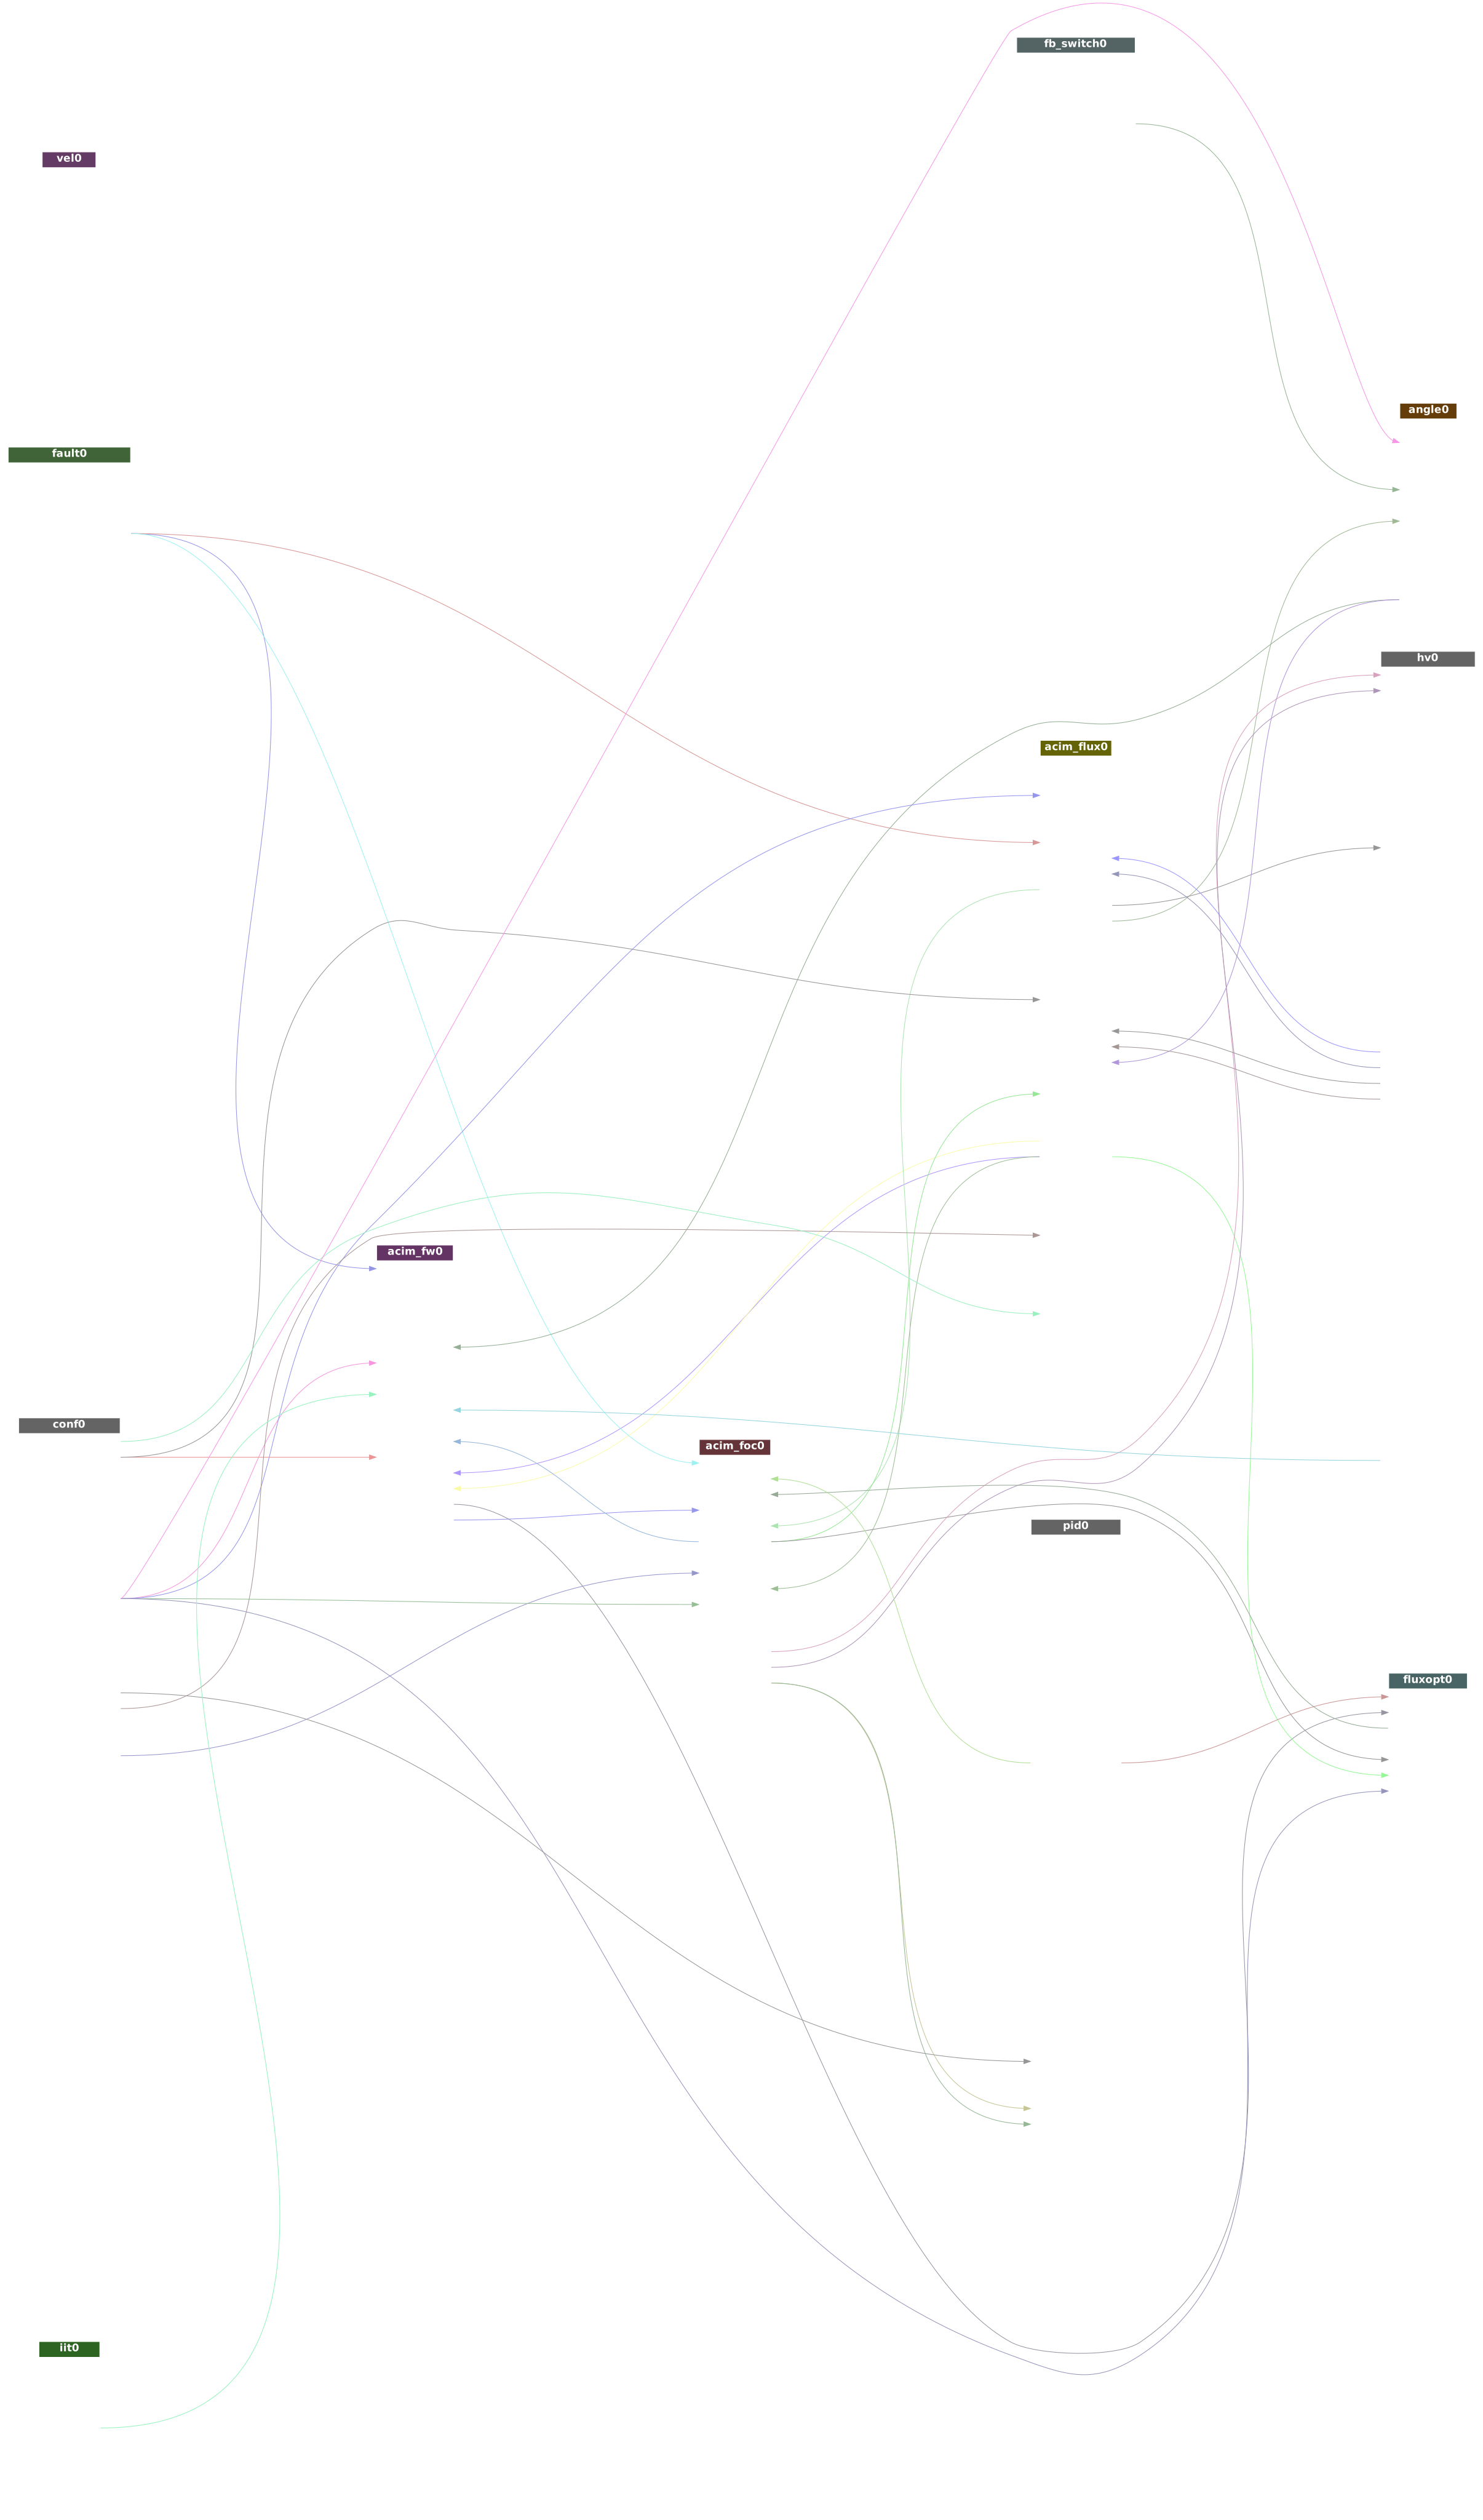
Source: Configuration File