FILTERS #
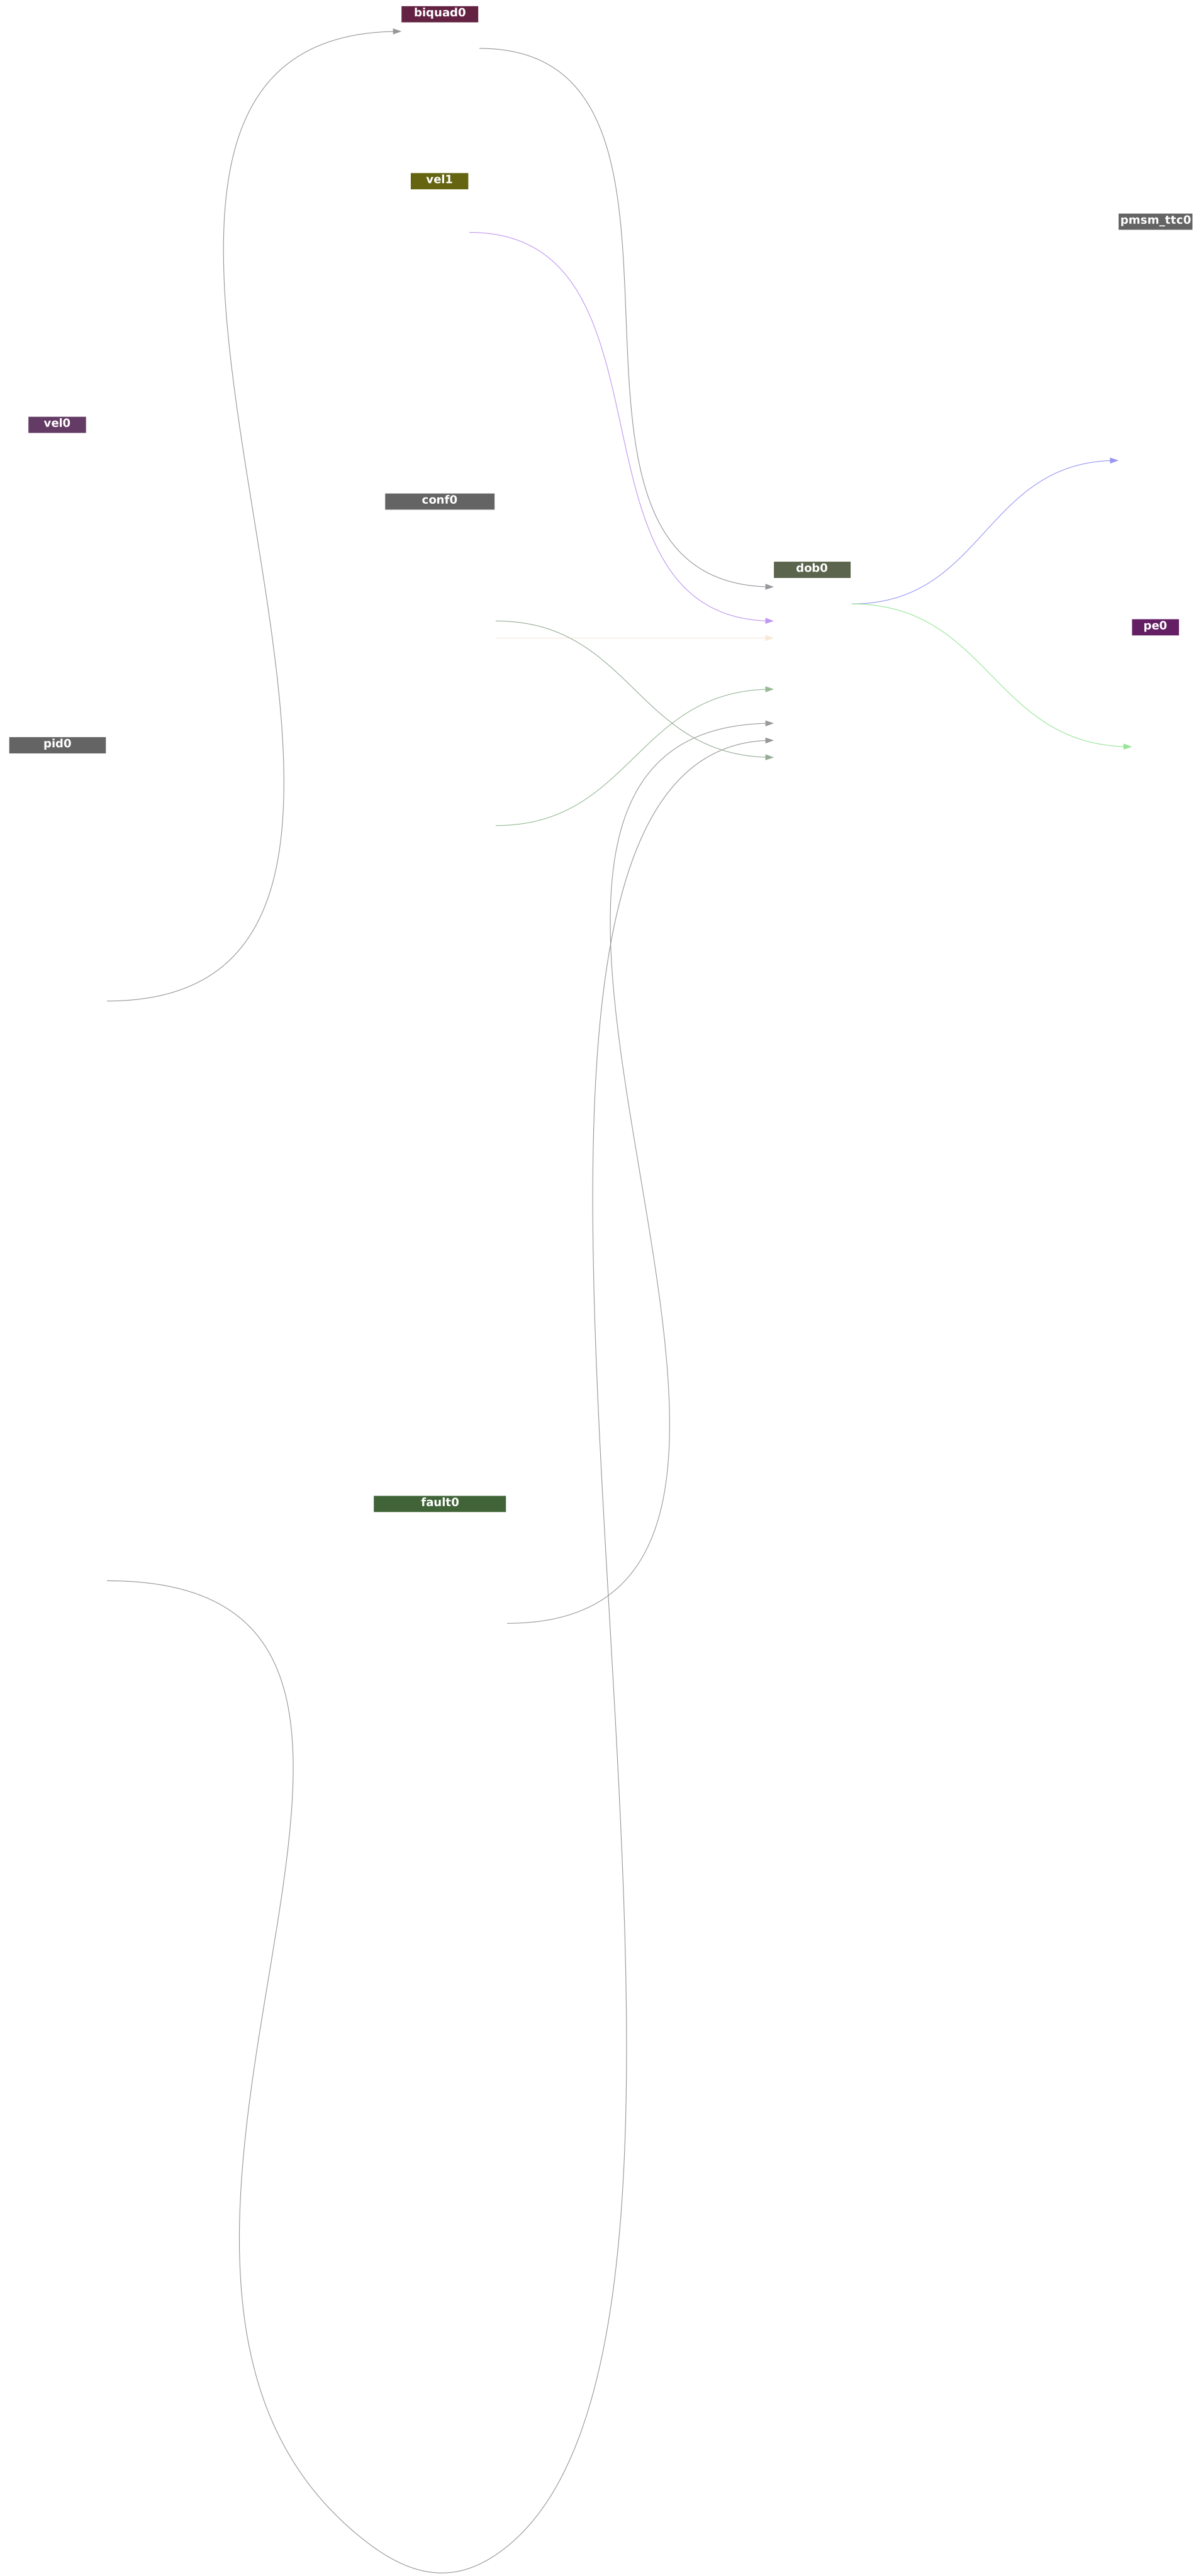
torque command filters, opt-in: link filters
(after link pmsm). pid0.torque_cmd -> biquad0
-> dob0 -> pmsm_ttc0; both pass through as set
here (biquad0.type 0, dob0.k 0).
rt_prio must be set before start: a comp
loaded at runtime without it never runs
(torque 0, fault 6 at enable). At runtime:
stop, link filters, start.
acim/dc: relink acim_ttc0 / acim_foc0 /
dc_ttc0 .torque to dob0.out instead.
Configuration Content #
# torque command filters, opt-in: link filters
# (after link pmsm). pid0.torque_cmd -> biquad0
# -> dob0 -> pmsm_ttc0; both pass through as set
# here (biquad0.type 0, dob0.k 0).
# rt_prio must be set before start: a comp
# loaded at runtime without it never runs
# (torque 0, fault 6 at enable). At runtime:
# stop, link filters, start.
# acim/dc: relink acim_ttc0 / acim_foc0 /
# dc_ttc0 .torque to dob0.out instead.
load biquad
load dob
biquad0.rt_prio = 8.3
dob0.rt_prio = 8.4
biquad0.in = pid0.torque_cmd
dob0.in = biquad0.out
pmsm_ttc0.torque = dob0.out
# observers see the filtered command
vel1.torque = dob0.out
vel2.torque = dob0.out
pe0.torque = dob0.out
# notch: type 1, f0 = frf0.f_res from an
# id_frf sweep that brackets one mode,
# q 2, depth 0..0.1. Only above crossover.
biquad0.type = 0
# dob: j = total inertia (id_frf 5-60 Hz
# total, or conf0.j + conf0.j_sys). k 1 needs
# conf0.f/d/o = 0: dob estimates friction too
# and k 1 with the friction ff counts it twice.
# dob0.k = 0 before id_mot / id_sys: dob cancels
# the friction and offset they measure.
dob0.vel = vel1.vel
# j_sys is a safe lower bound (j 0 with k 1
# feeds the command back on itself); set the
# total per axis before k 1
dob0.j = conf0.j_sys
dob0.en = fault0.en_pid
dob0.bw = 20
dob0.k = 0
dob0.max = conf0.max_force
# standstill hold with dob: pid0.hold_en 2. the
# hold slews the compensation so the torque goes
# to hold_o; with conf0.o 0 on a vertical axis
# set dob0.hold_o to the id_sys o. dob0.max must
# leave room: abs(o) + f or more
dob0.hold = pid0.hold
dob0.hold_o = conf0.o
Source: Configuration File