FLUX_OBS #
Spindle bench (14 Oct, no load): shadow within 0.03 rad cold; trim kp_s 20
ki_s 2 follows the rotor temperature (k 1.0 cold, 1.07-1.11 after 20 min
at 2352 rpm) and holds pos_err within 0.02 rad. Not tested under a
cutting load yet.
hybrid rotor flux observer (B5), for an induction motor on an encoder.
link after acim_foc: link flux_obs. Loads in shadow: flux_obs0.pos_err
shows how far the current model’s orientation is off at speed (tr).
To trim the slip with it: flux_obs0.kp_s 20, flux_obs0.ki_s 2 (k follows
the rotor temperature, minutes; faster chases load transients) and
angle0.slip = flux_obs0.slip; flux_obs0.k is then true/modelled slip.
flux_obs0.wc: crossover to the voltage model [rad/s electrical]
Configuration Content #
# Spindle bench (14 Oct, no load): shadow within 0.03 rad cold; trim kp_s 20
# ki_s 2 follows the rotor temperature (k 1.0 cold, 1.07-1.11 after 20 min
# at 2352 rpm) and holds pos_err within 0.02 rad. Not tested under a
# cutting load yet.
# hybrid rotor flux observer (B5), for an induction motor on an encoder.
# link after acim_foc: link flux_obs. Loads in shadow: flux_obs0.pos_err
# shows how far the current model's orientation is off at speed (tr).
# To trim the slip with it: flux_obs0.kp_s 20, flux_obs0.ki_s 2 (k follows
# the rotor temperature, minutes; faster chases load transients) and
# angle0.slip = flux_obs0.slip; flux_obs0.k is then true/modelled slip.
# flux_obs0.wc: crossover to the voltage model [rad/s electrical]
load flux_obs
flux_obs0.rt_prio = 9.4
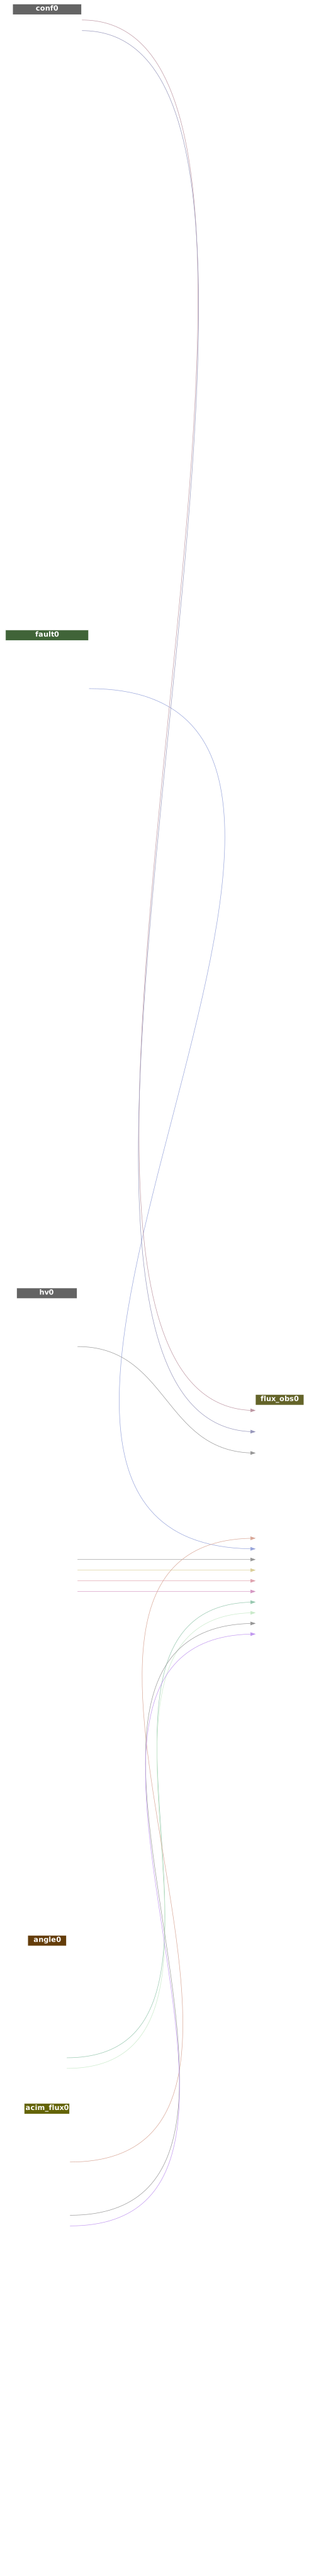
flux_obs0.en = fault0.en_out
flux_obs0.r = conf0.r
flux_obs0.l = conf0.l
flux_obs0.adv = hv0.adv
flux_obs0.id = hv0.id_fb
flux_obs0.iq = hv0.iq_fb
flux_obs0.ud = hv0.ud_fb
flux_obs0.uq = hv0.uq_fb
flux_obs0.pos_ref = angle0.pos
flux_obs0.vel_ref = angle0.vel
flux_obs0.psi_cm = acim_flux0.psi
flux_obs0.slip_in = acim_flux0.slip
flux_obs0.slip_max = acim_flux0.slip_max
Source: Configuration File