ID_BRK #
breakaway torque at standstill only (idm0.brk_only): the test id_sys
ends with, with the drive’s own gains and conf0.o in the feedforward.
the trajectory holds the axis where it stands, idm ramps an extra torque
(idm0.brk_rate, 3 Nm/s) until the axis moves idm0.brk_win (0.002 rad),
positive then negative, and prints the static friction (half the
difference) and the static load (the mean, gravity on a vertical axis)
next to conf0.f and conf0.o. the axis moves brk_win each way and comes
back; about 15 s on a vertical axis. the velocity integrator is parked
for the run (pid0.vel_d = idm0.vel_d_pid, 1e6 while ramping).
starts on enable; disable to abort or clear. run it with dob0.k = 0
(dob cancels the ramp) and the brake released.
Configuration Content #
# breakaway torque at standstill only (idm0.brk_only): the test id_sys
# ends with, with the drive's own gains and conf0.o in the feedforward.
# the trajectory holds the axis where it stands, idm ramps an extra torque
# (idm0.brk_rate, 3 Nm/s) until the axis moves idm0.brk_win (0.002 rad),
# positive then negative, and prints the static friction (half the
# difference) and the static load (the mean, gravity on a vertical axis)
# next to conf0.f and conf0.o. the axis moves brk_win each way and comes
# back; about 15 s on a vertical axis. the velocity integrator is parked
# for the run (pid0.vel_d = idm0.vel_d_pid, 1e6 while ramping).
# starts on enable; disable to abort or clear. run it with dob0.k = 0
# (dob cancels the ramp) and the brake released.
load idm
idm0.rt_prio = 4
idm0.brk_only = 1
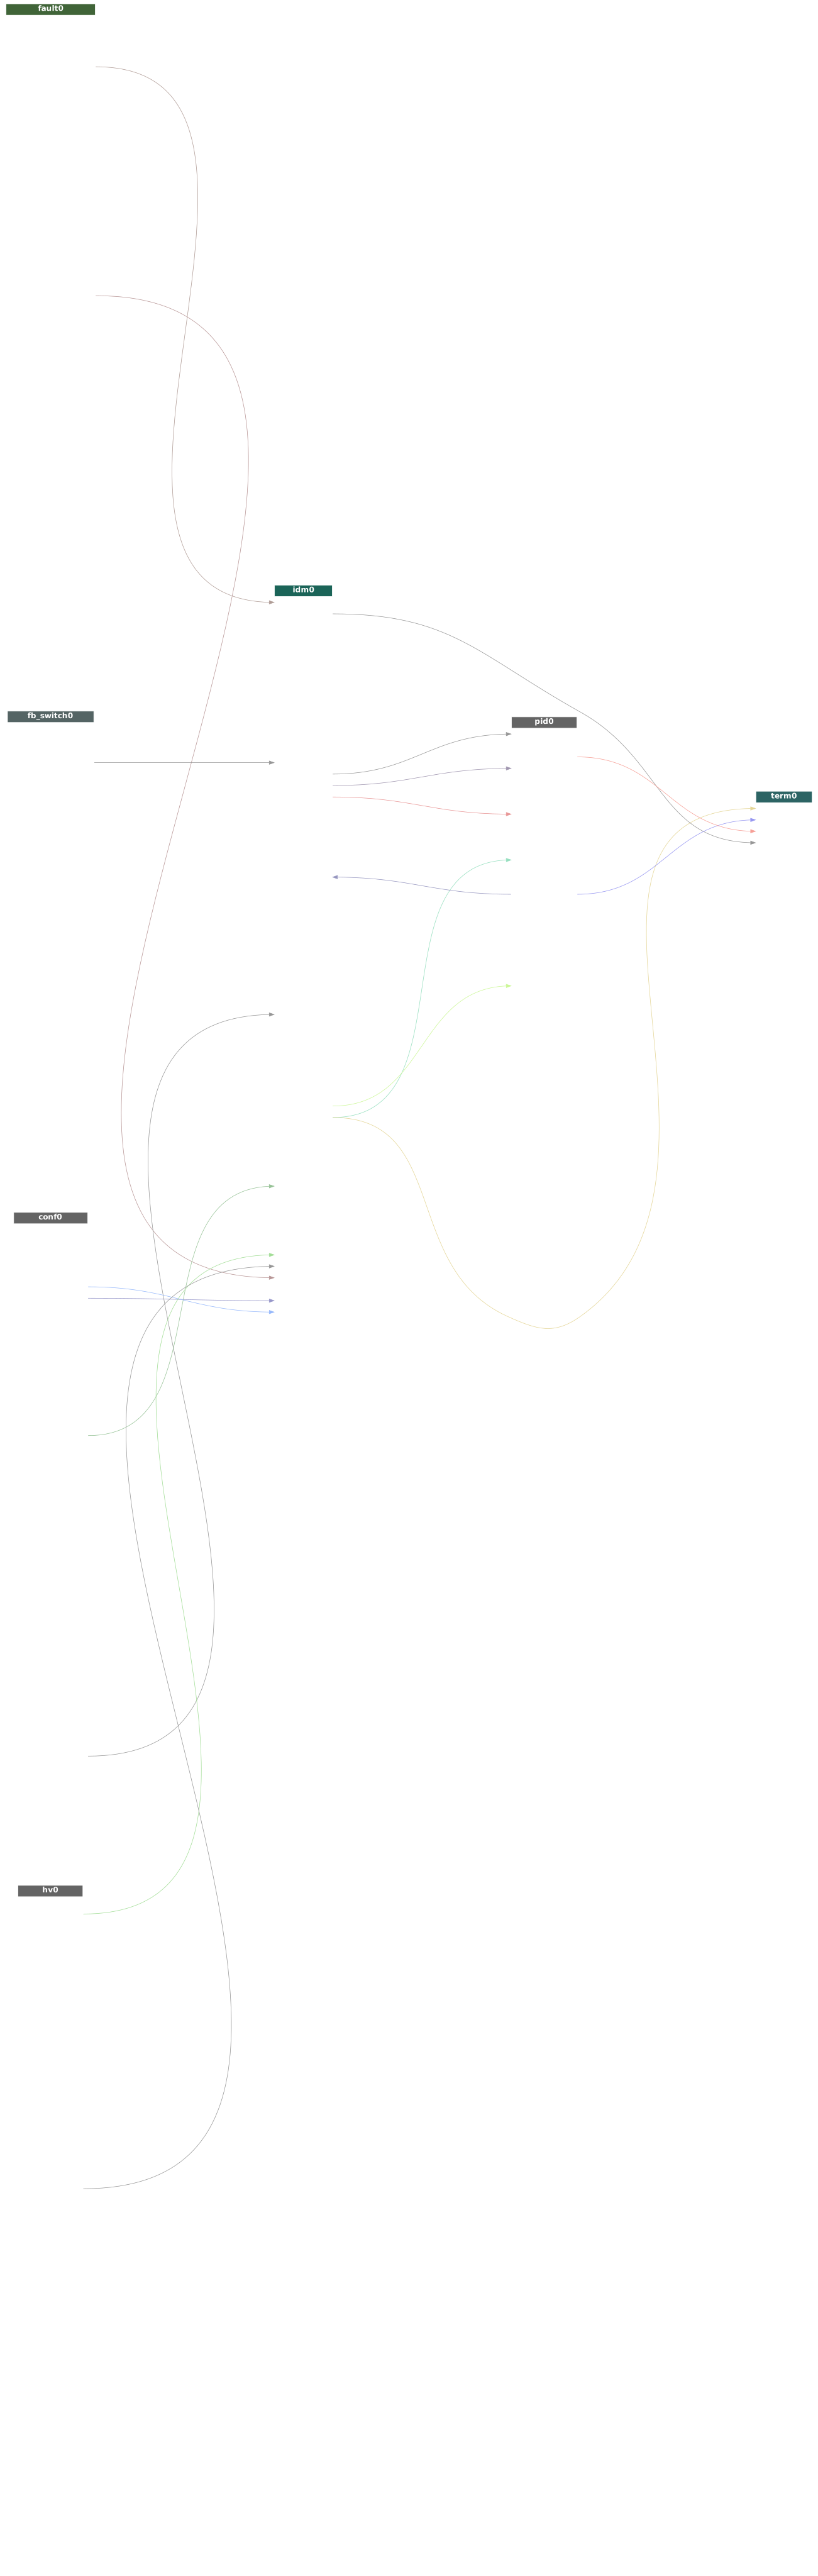
idm0.en = fault0.en_out
idm0.pos_fb = fb_switch0.pos_fb
pid0.pos_ext_cmd = idm0.pos_cmd
pid0.vel_ext_cmd = idm0.vel_cmd
pid0.acc_ext_cmd = idm0.acc_cmd
pid0.torque_ext_cmd = idm0.torque_ext
idm0.torque = pid0.torque_cmd
idm0.vel_d = conf0.vel_d
pid0.vel_d = idm0.vel_d_pid
idm0.brk_max = conf0.max_force
idm0.o_ref = conf0.o
idm0.f_ref = conf0.f
# stop on a derated current (brk_res -2) and read the torque the current makes
idm0.cur_cmd = hv0.q_cmd
idm0.cur_fb = hv0.iq_fb
idm0.scale = fault0.scale

term0.wave0 = idm0.torque_ext
term0.gain0 = 10
term0.wave1 = pid0.torque_cmd
term0.gain1 = 10
term0.wave2 = pid0.pos_error
term0.gain2 = 2000
term0.wave3 = idm0.state
term0.gain3 = 10
Source: Configuration File