ID_DAC #
one shot hv0.dac search: prints hv0.dac for a trip at iddac0.cur
set conf0.max_ac_cur over 1.05 x cur (1.2 x in mode 1) first; reset afterwards
Configuration Content #
# one shot hv0.dac search: prints hv0.dac for a trip at iddac0.cur
# set conf0.max_ac_cur over 1.05 x cur (1.2 x in mode 1) first; reset afterwards
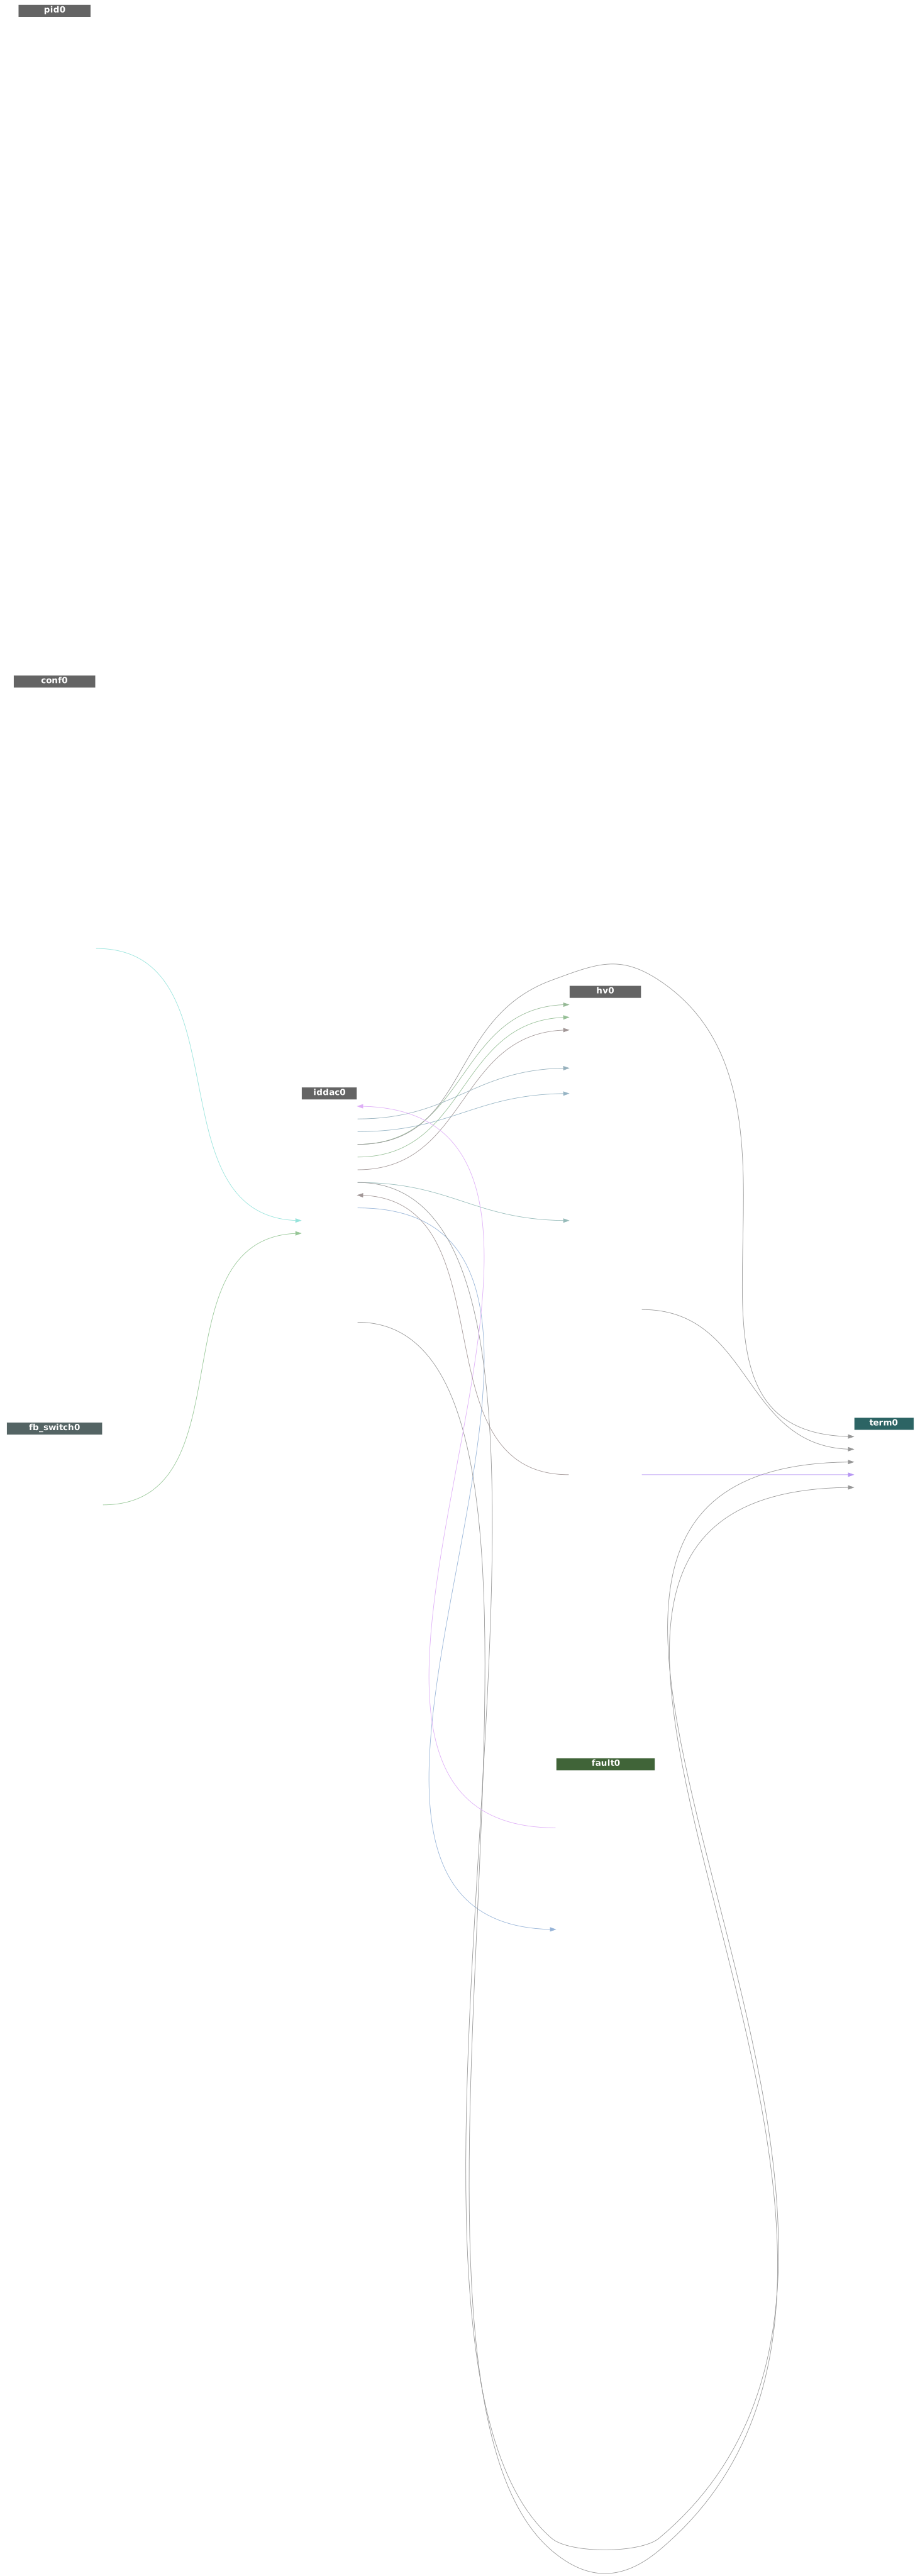
load iddac
iddac0.rt_prio = 4
iddac0.en = fault0.en_out
fault0.pos_error = 0
fault0.sat = 0
pid0.en = 0
fault0.hv_error = iddac0.hv_error
iddac0.hv_fault = hv0.fault
iddac0.max_cur = conf0.max_ac_cur
iddac0.com_pos = fb_switch0.com_fb
hv0.en = iddac0.en_out
hv0.cmd_mode = iddac0.cmd_mode
hv0.d_cmd = iddac0.d_cmd
hv0.q_cmd = iddac0.q_cmd
hv0.pos = iddac0.pos
hv0.dac = iddac0.dac
# 0 free axis (three angles), 1 loaded or blocked axis (rotor d axis)
iddac0.mode = 1
iddac0.cur = 20
# fast ramp: a slow one heats ipm0's junction model at a fixed angle and
# clamps the current before high trips (Z, 25 A at 20 A/s, 21 Oct)
iddac0.ramp = 200
# scope: current command and feedback (4/A), dac under test (0.25/count),
# hv fault code (4/code, 16 = HW overcurrent trip), search state (20/state)
term0.wave0 = iddac0.d_cmd
term0.gain0 = 4
term0.wave1 = hv0.id_fb
term0.gain1 = 4
term0.wave2 = iddac0.dac
term0.gain2 = 0.25
term0.wave3 = hv0.fault
term0.gain3 = 4
term0.wave4 = iddac0.state
term0.gain4 = 20
Source: Configuration File