ID_FRF #
measure the coupling with a stepped-sine FRF (comp frf) for conf0.j_lpf.
replaces id_lpf’s ring down: it fits a two-mass model to the whole curve
instead of timing one ring. needs the axis free to move: it goes back and
forth at frf0.creep_vel between frf0.min_pos and frf0.max_pos about where
it starts (both sides, rad), measures only while cruising, and ends where
it started. the sweep prints a table, then the fit and conf0.j_lpf.
creep_vel 3 rad/s keeps the load sliding through the sine near the
anti-resonance, where it swings most (1 rad/s read the mode 10 % low in
the sim). the lowest point needs one cruise: (max_pos - min_pos) / creep_vel
has to exceed about 3 s at f_start 5 Hz.
starts on enable like the other id templates (frf0.start follows the pid
enable, so the creep starts once the loop runs); disable to abort or to
clear a finished sweep. unlinked, frf0.start = 1 / 0 starts and stops it.
run it before id_pid: j_lpf changes the plant the gains are tuned against.
Configuration Content #
# measure the coupling with a stepped-sine FRF (comp frf) for conf0.j_lpf.
# replaces id_lpf's ring down: it fits a two-mass model to the whole curve
# instead of timing one ring. needs the axis free to move: it goes back and
# forth at frf0.creep_vel between frf0.min_pos and frf0.max_pos about where
# it starts (both sides, rad), measures only while cruising, and ends where
# it started. the sweep prints a table, then the fit and conf0.j_lpf.
# creep_vel 3 rad/s keeps the load sliding through the sine near the
# anti-resonance, where it swings most (1 rad/s read the mode 10 % low in
# the sim). the lowest point needs one cruise: (max_pos - min_pos) / creep_vel
# has to exceed about 3 s at f_start 5 Hz.
# starts on enable like the other id templates (frf0.start follows the pid
# enable, so the creep starts once the loop runs); disable to abort or to
# clear a finished sweep. unlinked, frf0.start = 1 / 0 starts and stops it.
# run it before id_pid: j_lpf changes the plant the gains are tuned against.
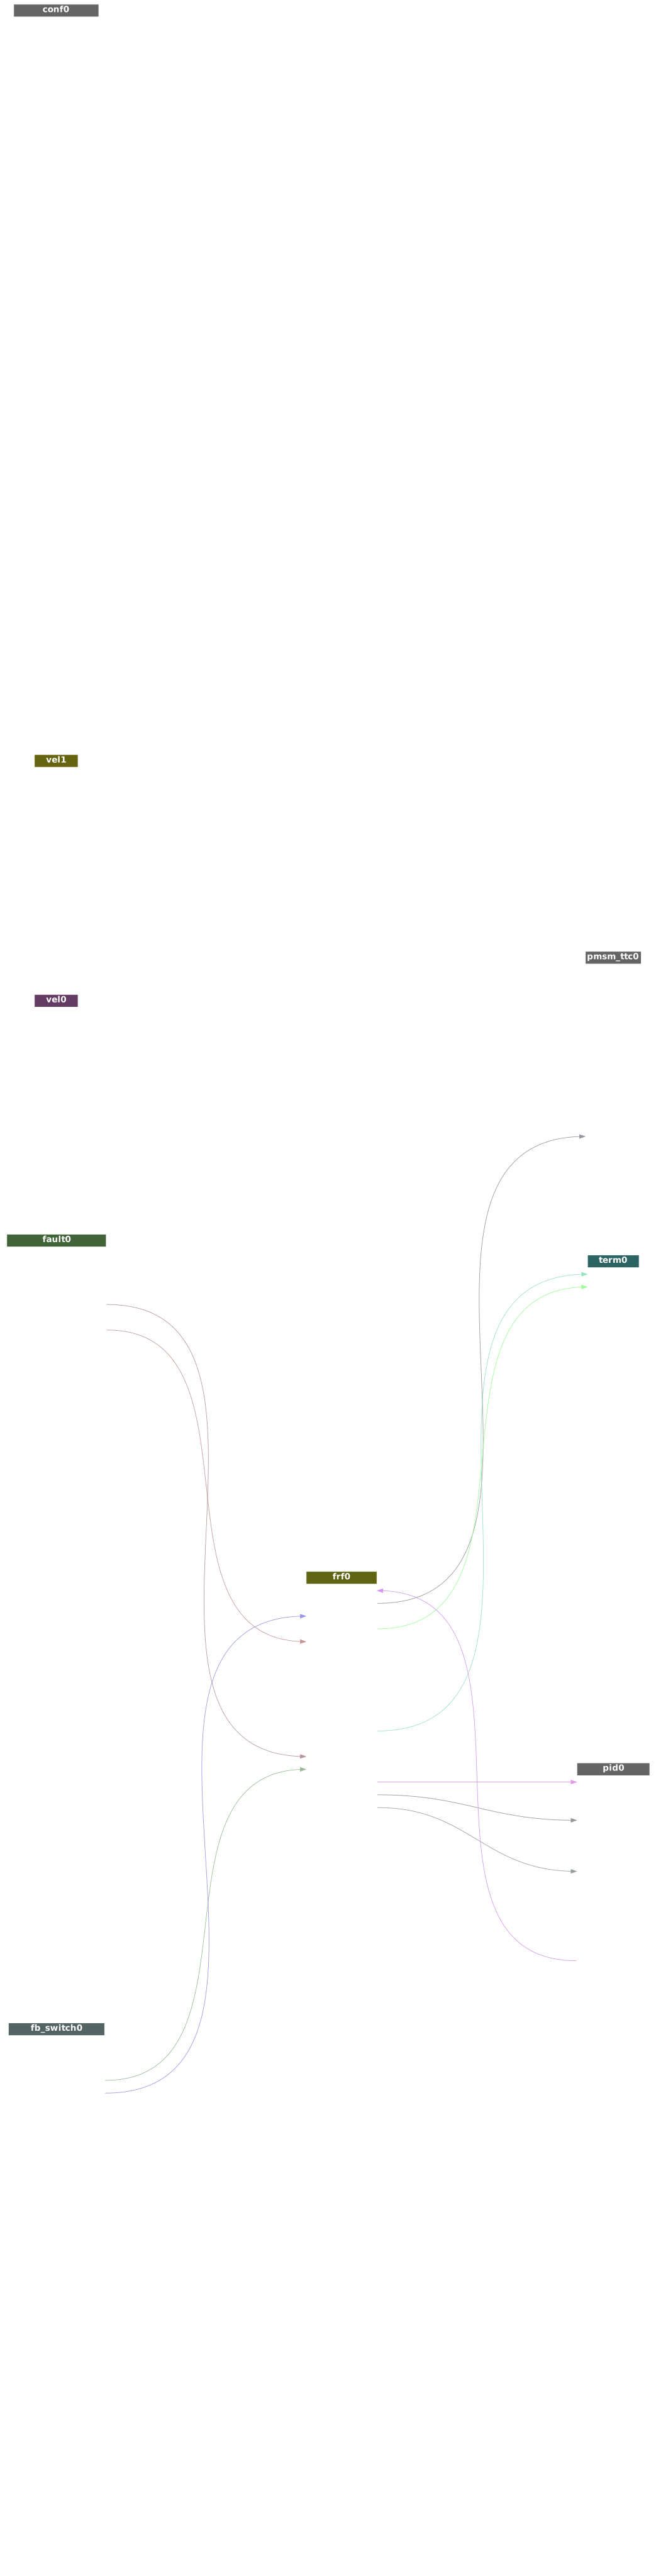
load frf
frf0.rt_prio = 8.6
frf0.en = fault0.en_out
frf0.start = fault0.en_pid
frf0.pos_fb = fb_switch0.pos_fb
pid0.pos_ext_cmd = frf0.pos_cmd
pid0.vel_ext_cmd = frf0.vel_cmd
pid0.acc_ext_cmd = frf0.acc_cmd

frf0.in = pid0.torque_cmd
pmsm_ttc0.torque = frf0.out
frf0.pos = fb_switch0.vel_fb
vel1.torque = frf0.out
vel2.torque = frf0.out

frf0.amp = 1
frf0.creep_vel = 3
frf0.creep_acc = 20
frf0.min_pos = -10
frf0.max_pos = 10

conf0.max_pos_error = 0

term0.wave0 = frf0.freq
term0.gain0 = 1
term0.wave1 = frf0.inj
term0.gain1 = 20
Source: Configuration File