ID_TUNE #
Configuration Content #
load idtune
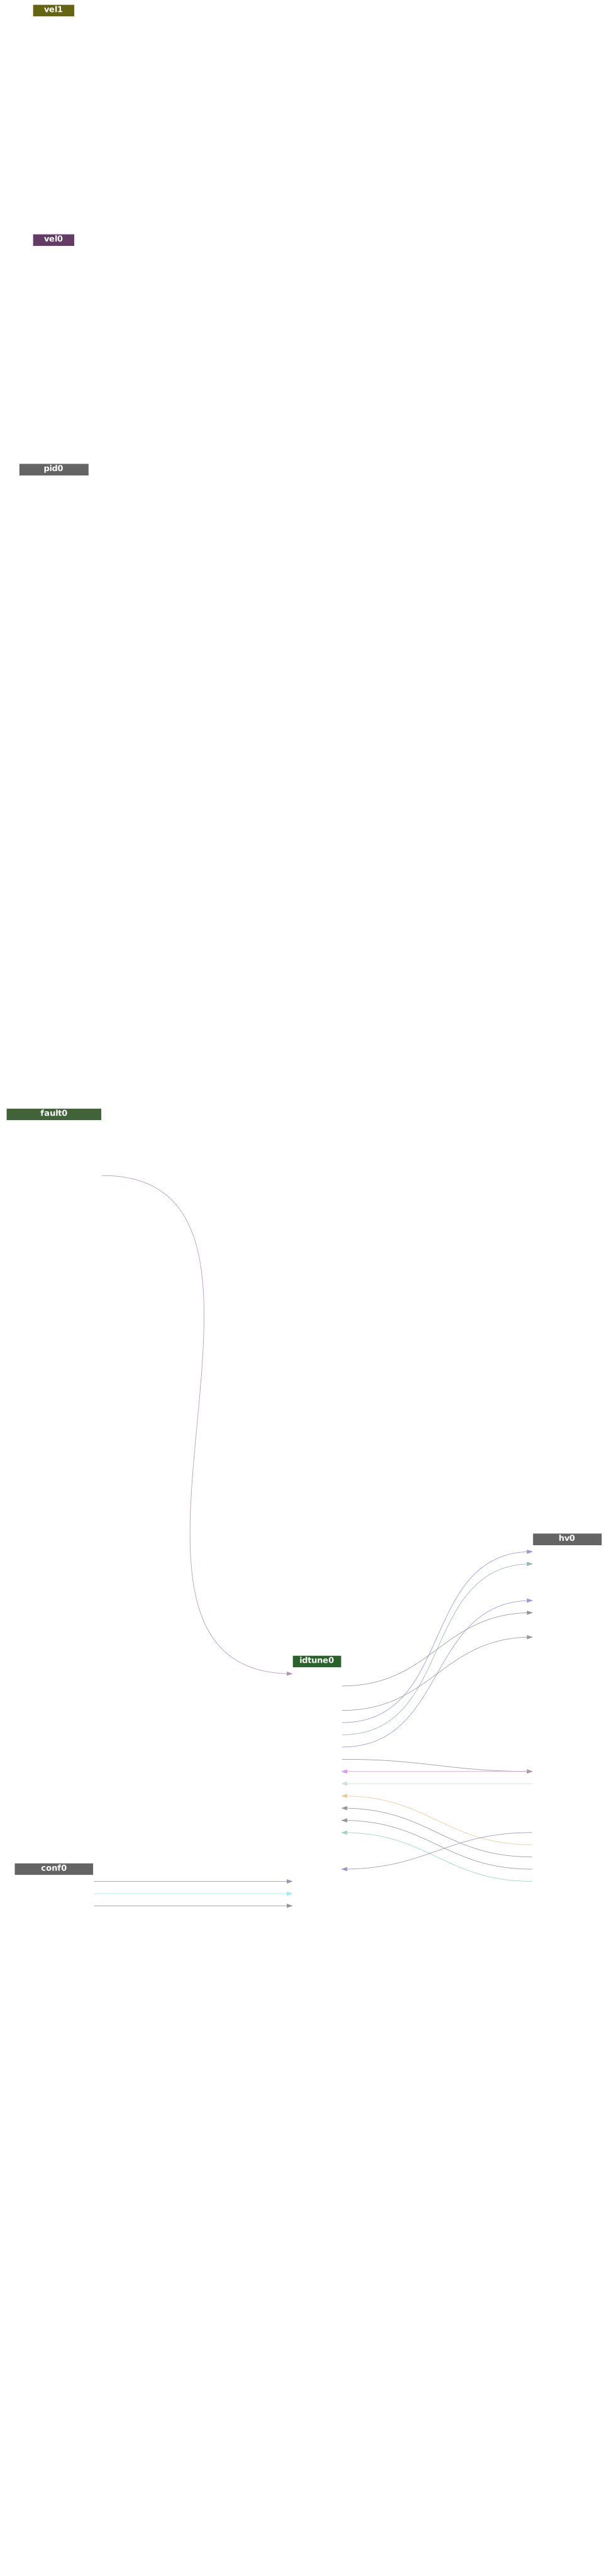
idtune0.rt_prio = 4

# run after id_pmsm, with its results in the config. hv0.pos and hv0.vel stay
# on the running path, so the angle tuned is the angle that runs.
idtune0.en = fault0.en_out
fault0.pos_error = 0
fault0.sat = 0
pid0.en = 0
hv0.en = idtune0.en_out
hv0.cmd_mode = idtune0.cmd_mode
hv0.d_cmd = idtune0.d_cmd
hv0.q_cmd = idtune0.q_cmd
hv0.adv = idtune0.adv
# before hv0.drop_k is pointed at id_tune: the config's drop_k, kept when
# drop_knee > 0
idtune0.drop_k_cfg = hv0.drop_k
idtune0.drop_knee = hv0.drop_knee
hv0.drop_k = idtune0.drop_k
idtune0.ud_fb = hv0.ud_fb
idtune0.uq_fb = hv0.uq_fb
idtune0.id_fb = hv0.id_fb
idtune0.iq_fb = hv0.iq_fb
idtune0.dc_volt = hv0.dc_volt
idtune0.vel_fb = vel1.vel
idtune0.vel_e = vel2.vel
idtune0.r = conf0.r
idtune0.l = conf0.l
idtune0.lq = conf0.lq
Source: Configuration File