SL_ACIM #
induction motor sensorless: link pid, link acim_foc, link sl_acim.
obs uses conf0.l = sigma*Ls for both axes (conf0.lq 0). chk_err is not
meaningful here: the encoder angle is the rotor’s, not the flux’s.
From the motor values: i_f = id_n, align_time 3 * tr, w_hand where the
emf is 5 * obs0.e_min, hyst w_hand / 3 (sl_seq0.align, hand show them);
a value in the config wins. obs0.bw = 5 * w_hand * polecount (sl_seq0.obs_bw).
Optional, with a spindle encoder: sl_seq0.vel_enc = <encoder speed,
e.g. vel1.vel>, sl_seq0.enc_tol 1 (multiple of acim_flux0.slip_max);
then acim_flux0.tr_ks 1 trims tr from the slip error in steady holds.
command through ramp0: sl_seq0.vel_cmd = ramp0.vel_cmd (sensorless
links vel0.vel); pid takes sl_seq0.vel_ref, keep no pid0.vel_ext_cmd line.
Configuration Content #
# induction motor sensorless: link pid, link acim_foc, link sl_acim.
# obs uses conf0.l = sigma*Ls for both axes (conf0.lq 0). chk_err is not
# meaningful here: the encoder angle is the rotor's, not the flux's.
# From the motor values: i_f = id_n, align_time 3 * tr, w_hand where the
# emf is 5 * obs0.e_min, hyst w_hand / 3 (sl_seq0.align, hand show them);
# a value in the config wins. obs0.bw = 5 * w_hand * polecount (sl_seq0.obs_bw).
# Optional, with a spindle encoder: sl_seq0.vel_enc = <encoder speed,
# e.g. vel1.vel>, sl_seq0.enc_tol 1 (multiple of acim_flux0.slip_max);
# then acim_flux0.tr_ks 1 trims tr from the slip error in steady holds.
# command through ramp0: sl_seq0.vel_cmd = ramp0.vel_cmd (sensorless
# links vel0.vel); pid takes sl_seq0.vel_ref, keep no pid0.vel_ext_cmd line.
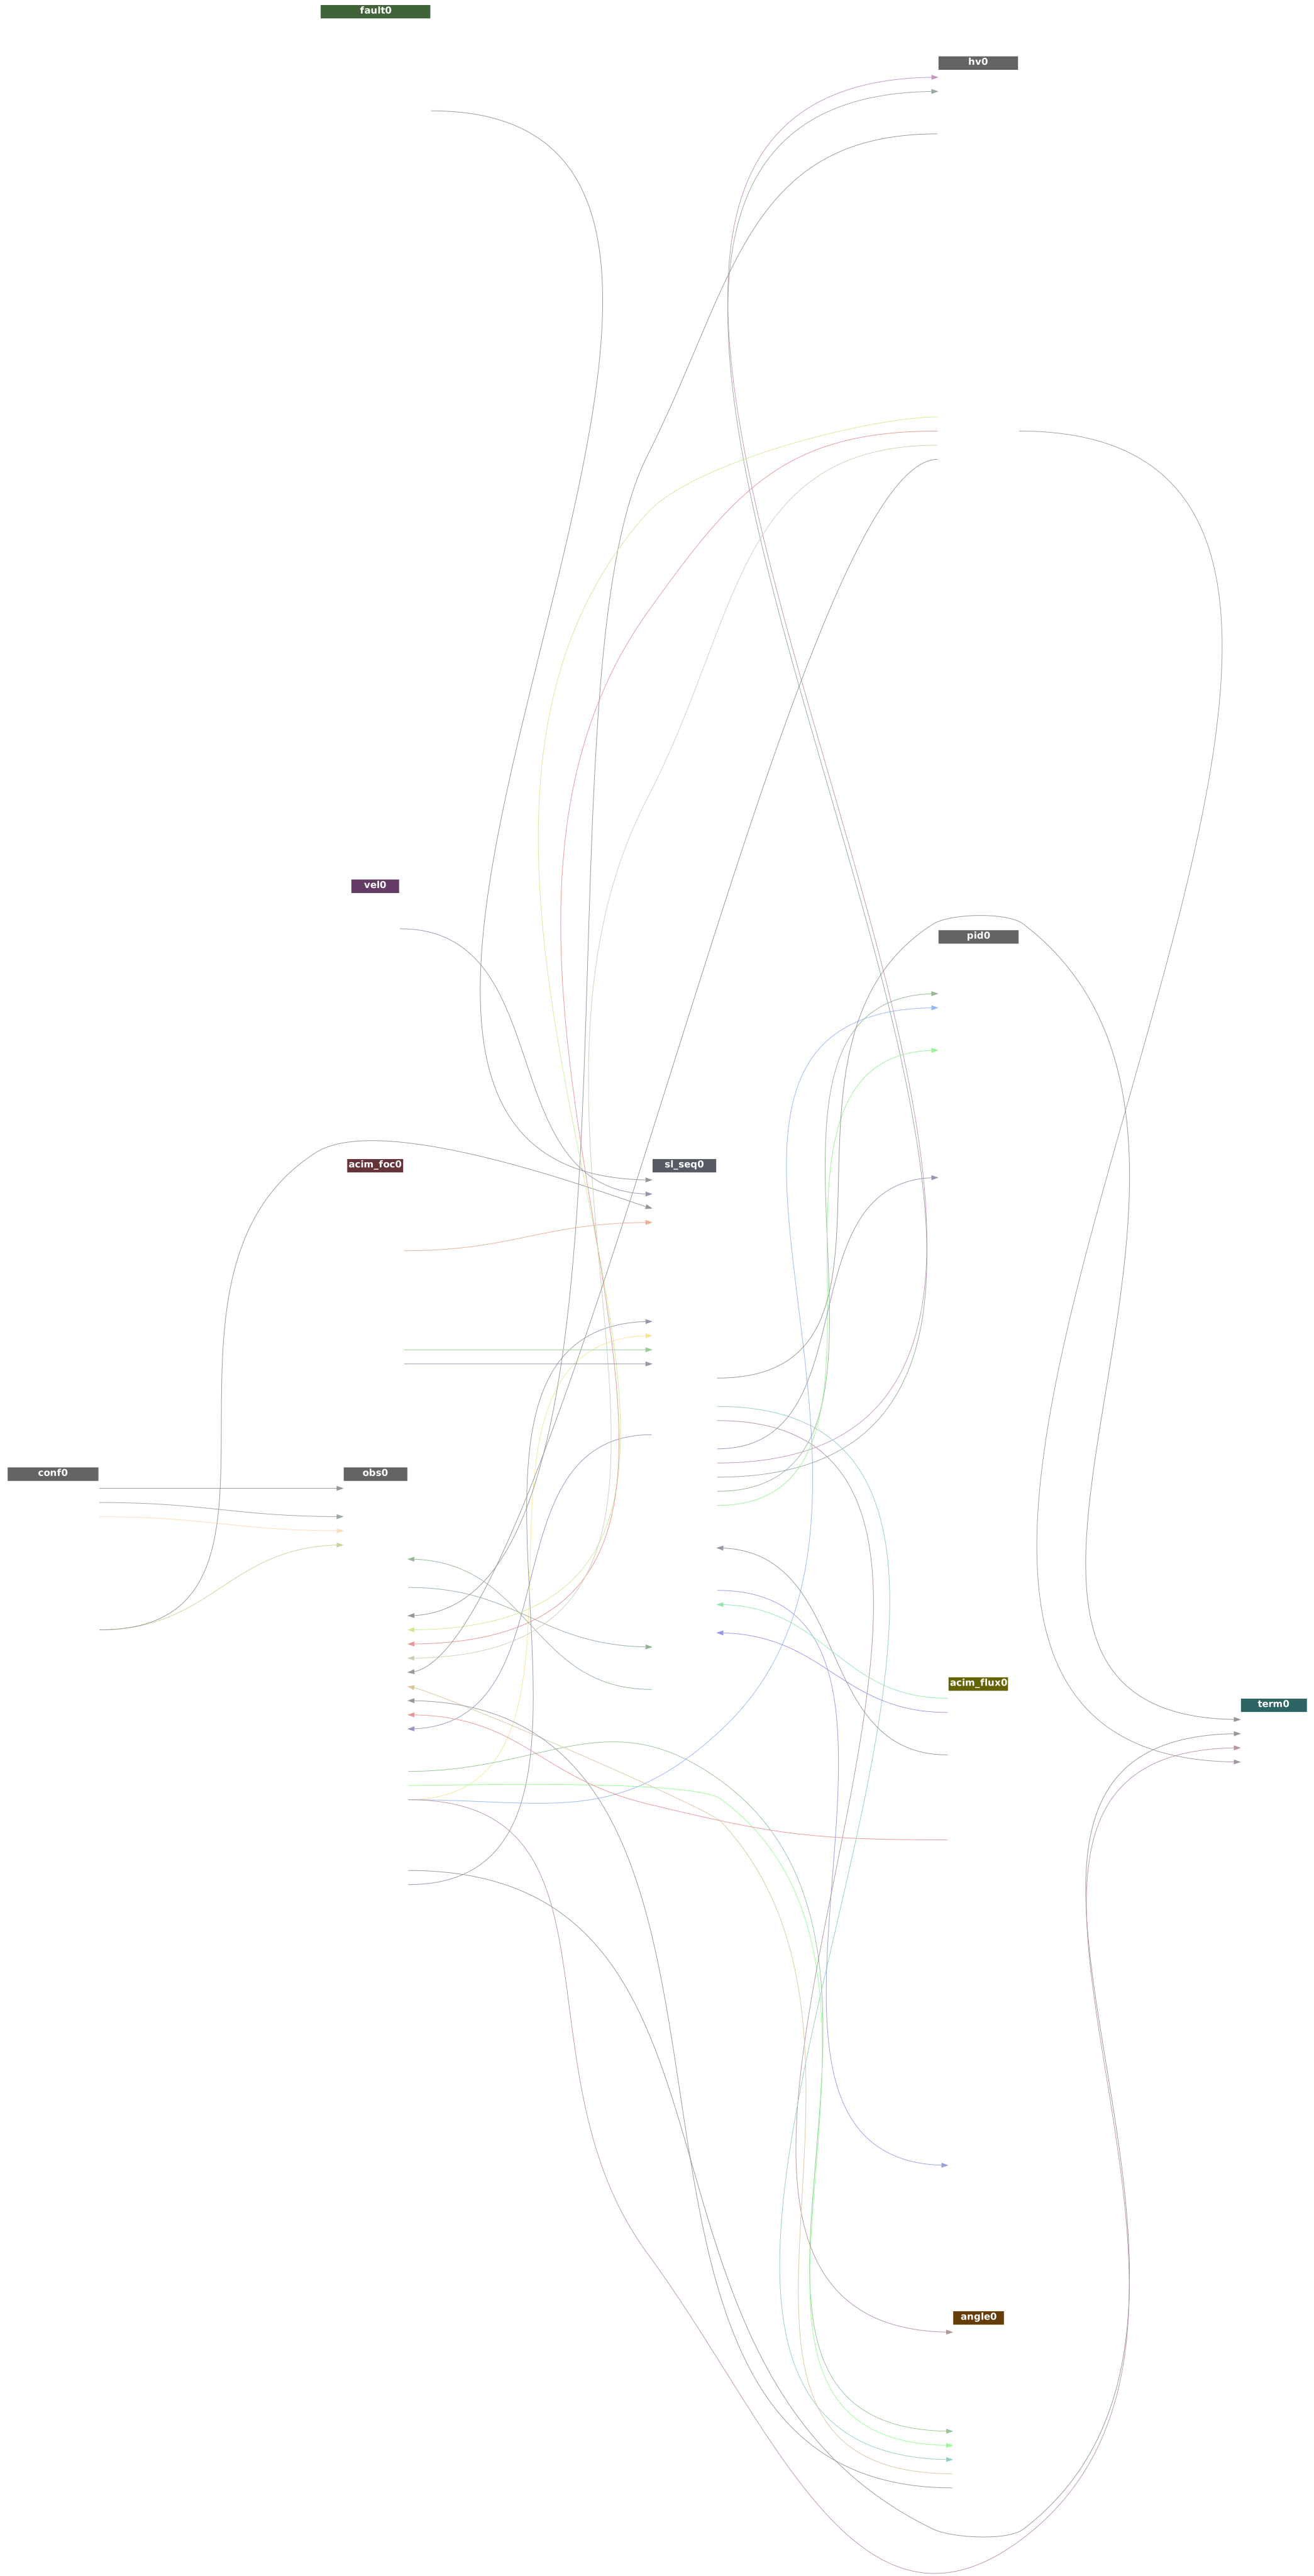
link sensorless
sl_seq0.i_f = acim_foc0.id_n
sl_seq0.tr = acim_flux0.tr
sl_seq0.lmr = acim_flux0.lmr
sl_seq0.d_in = acim_foc0.d_cmd
sl_seq0.q_in = acim_foc0.q_cmd
obs0.slip = acim_flux0.slip
sl_seq0.slip_max = acim_flux0.slip_max
obs0.bw = sl_seq0.obs_bw
acim_flux0.slip_err = sl_seq0.slip_err
# no tr MRAS here: the observer frame does not depend on tr, so the
# reactive power residual has no tr in it and the MRAS would only drift
acim_flux0.tr_ki = 0
Source: Configuration File