VF #
induction motor, open loop V/f, no feedback needed.
replaces uf for new configs. speed: vf0.vel_cmd [rad/s mech]
set vf0.u_n (phase peak V at vf0.vel_n), u_boost, i_stall
encoder slip control: link vf_enc instead (or vf0.vel_fb =
vf0.enc 1, vf0.slip_max (0 = 2 * slip_n); tune vf0.enc_kp / enc_ki.
Configuration Content #
# induction motor, open loop V/f, no feedback needed.
# replaces uf for new configs. speed: vf0.vel_cmd [rad/s mech]
# set vf0.u_n (phase peak V at vf0.vel_n), u_boost, i_stall
# encoder slip control: link vf_enc instead (or vf0.vel_fb = <rotor speed>,
# vf0.enc 1, vf0.slip_max (0 = 2 * slip_n); tune vf0.enc_kp / enc_ki.
load adc
load fault
load hv
load sim
load io
load iit
load vf
load angle
link conf
adc0.rt_prio = 1
io0.rt_prio = 7
vf0.rt_prio = 8
angle0.rt_prio = 9.5
hv0.rt_prio = 10
fault0.rt_prio = 10
iit0.rt_prio = 13
sim0.rt_prio = 13
term0.rt_prio = 16
fault0.max_dc_cur = conf0.max_dc_cur
fault0.max_ac_cur = conf0.max_ac_cur
fault0.max_dc_volt = conf0.max_dc_volt
fault0.high_dc_volt = conf0.high_dc_volt
fault0.min_dc_volt = conf0.low_dc_volt
fault0.max_hv_temp = conf0.max_hv_temp
fault0.max_mot_temp = conf0.max_mot_temp
fault0.high_hv_temp = conf0.high_hv_temp
fault0.high_mot_temp = conf0.high_mot_temp
fault0.fan_hv_temp = conf0.fan_hv_temp
fault0.fan_mot_temp = conf0.fan_mot_temp
fault0.ac_cur = hv0.abs_cur
fault0.dc_volt = hv0.dc_volt
fault0.hv_temp = hv0.hv_temp
fault0.dc_cur = hv0.dc_cur
fault0.hv_error = hv0.fault
fault0.fb_ready = 1
fault0.mot_temp = iit0.temp
hv0.rev = conf0.out_rev
hv0.r = conf0.r
hv0.l = conf0.l
hv0.lq = conf0.lq
hv0.psi = 0
hv0.cur_bw = conf0.cur_bw
hv0.max_cur = conf0.max_ac_cur
hv0.en = fault0.en_out
hv0.scale = fault0.scale
hv0.cmd_mode = 0
hv0.phase_mode = 2
vf0.en = fault0.en_out
vf0.polecount = conf0.polecount
vf0.scale = fault0.scale
vf0.id = hv0.id_fb
vf0.iq = hv0.iq_fb
vf0.ud = hv0.ud_fb
vf0.uq = hv0.uq_fb
vf0.dc_volt = hv0.dc_volt
vf0.pwm_volt = hv0.pwm_volt
vf0.dc_hold = conf0.high_dc_volt
# standstill boost: covers the dead time drop (no compensation in volt
# mode) plus r * the magnetizing current, so the encoder path (enc 1) starts
# from rest on the slip frequency alone. 12 V on the spindle (IM06B50GC1,
# drop ~8.7 V); set it in the config for other motors
vf0.u_boost = 12
angle0.src = 3
angle0.vel_cmd = vf0.vel_e
hv0.d_cmd = vf0.u_cmd
hv0.q_cmd = 0
hv0.pos = angle0.pos
hv0.vel = angle0.vel
io0.fan = fault0.hv_fan
io0.fault = fault0.fault
io0.state = fault0.state
iit0.max_temp = conf0.max_mot_temp
iit0.high_temp = conf0.high_mot_temp
iit0.max_cur = conf0.max_ac_cur
iit0.cur = hv0.abs_cur
# bridge junction model and derate, conf0.high_ipm_temp and max_ipm_temp
link ipm
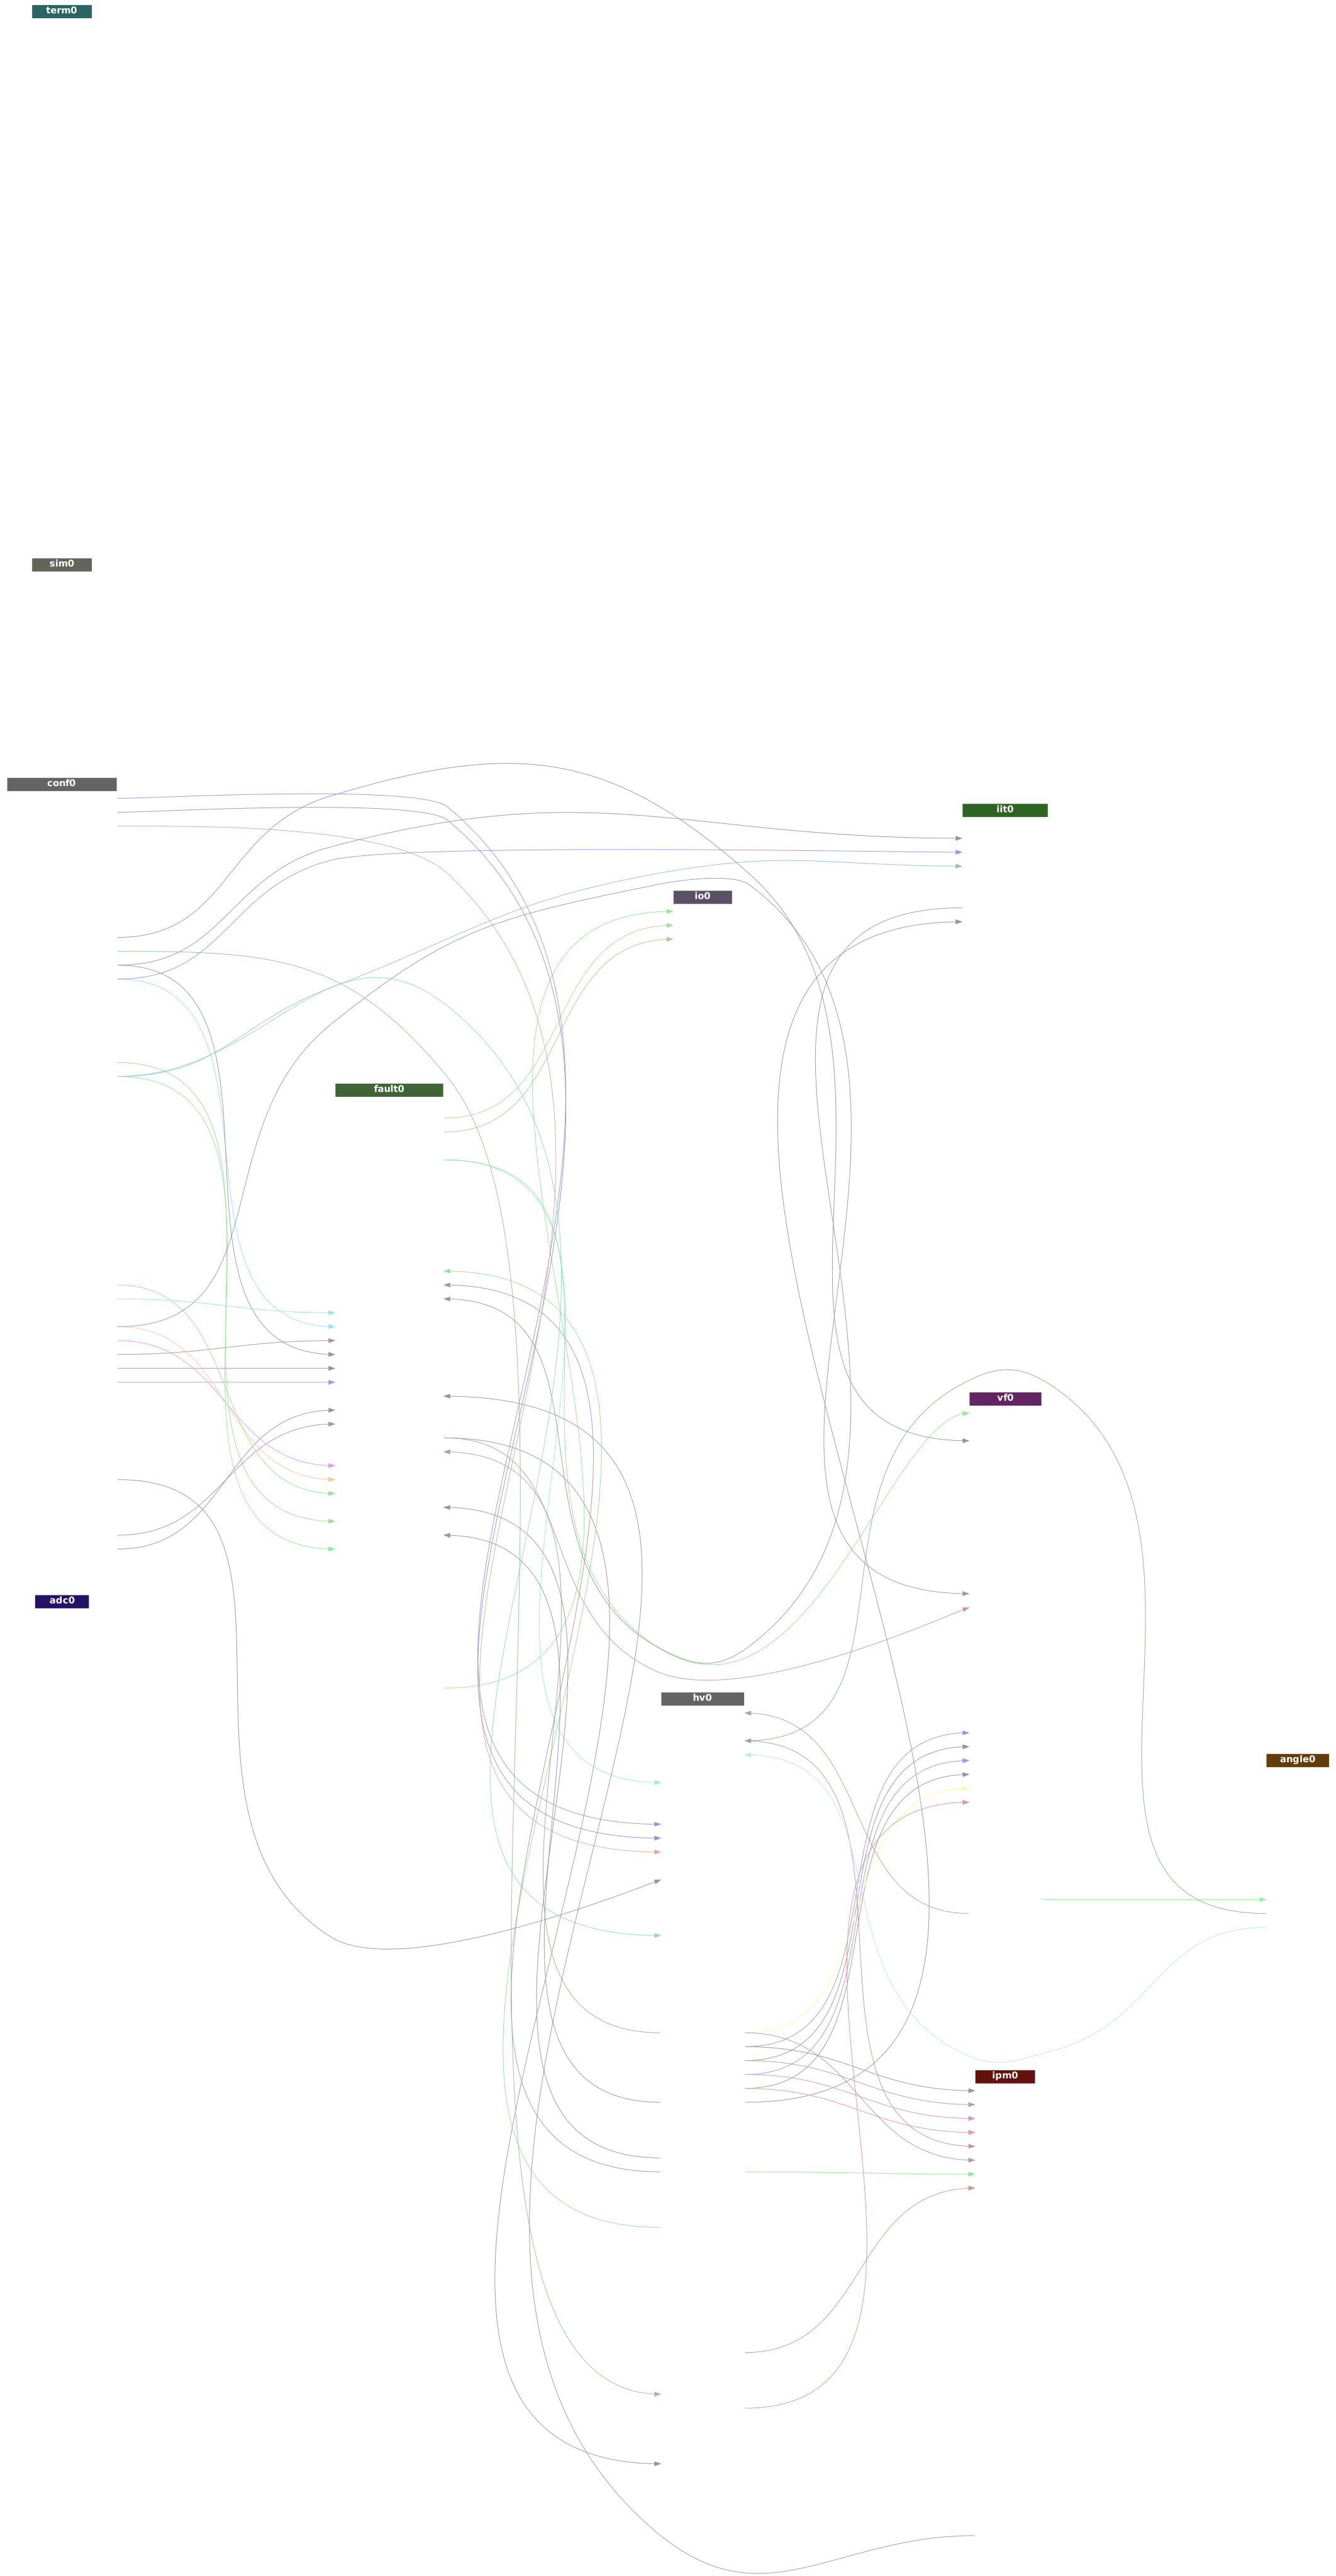
Source: Configuration File